Photos and videos
Gallery
The hand as it takes shape: printed parts, tendons, electronics and the first moves.
Photos and screenshots from the build so far. More will follow as the prototype comes together.
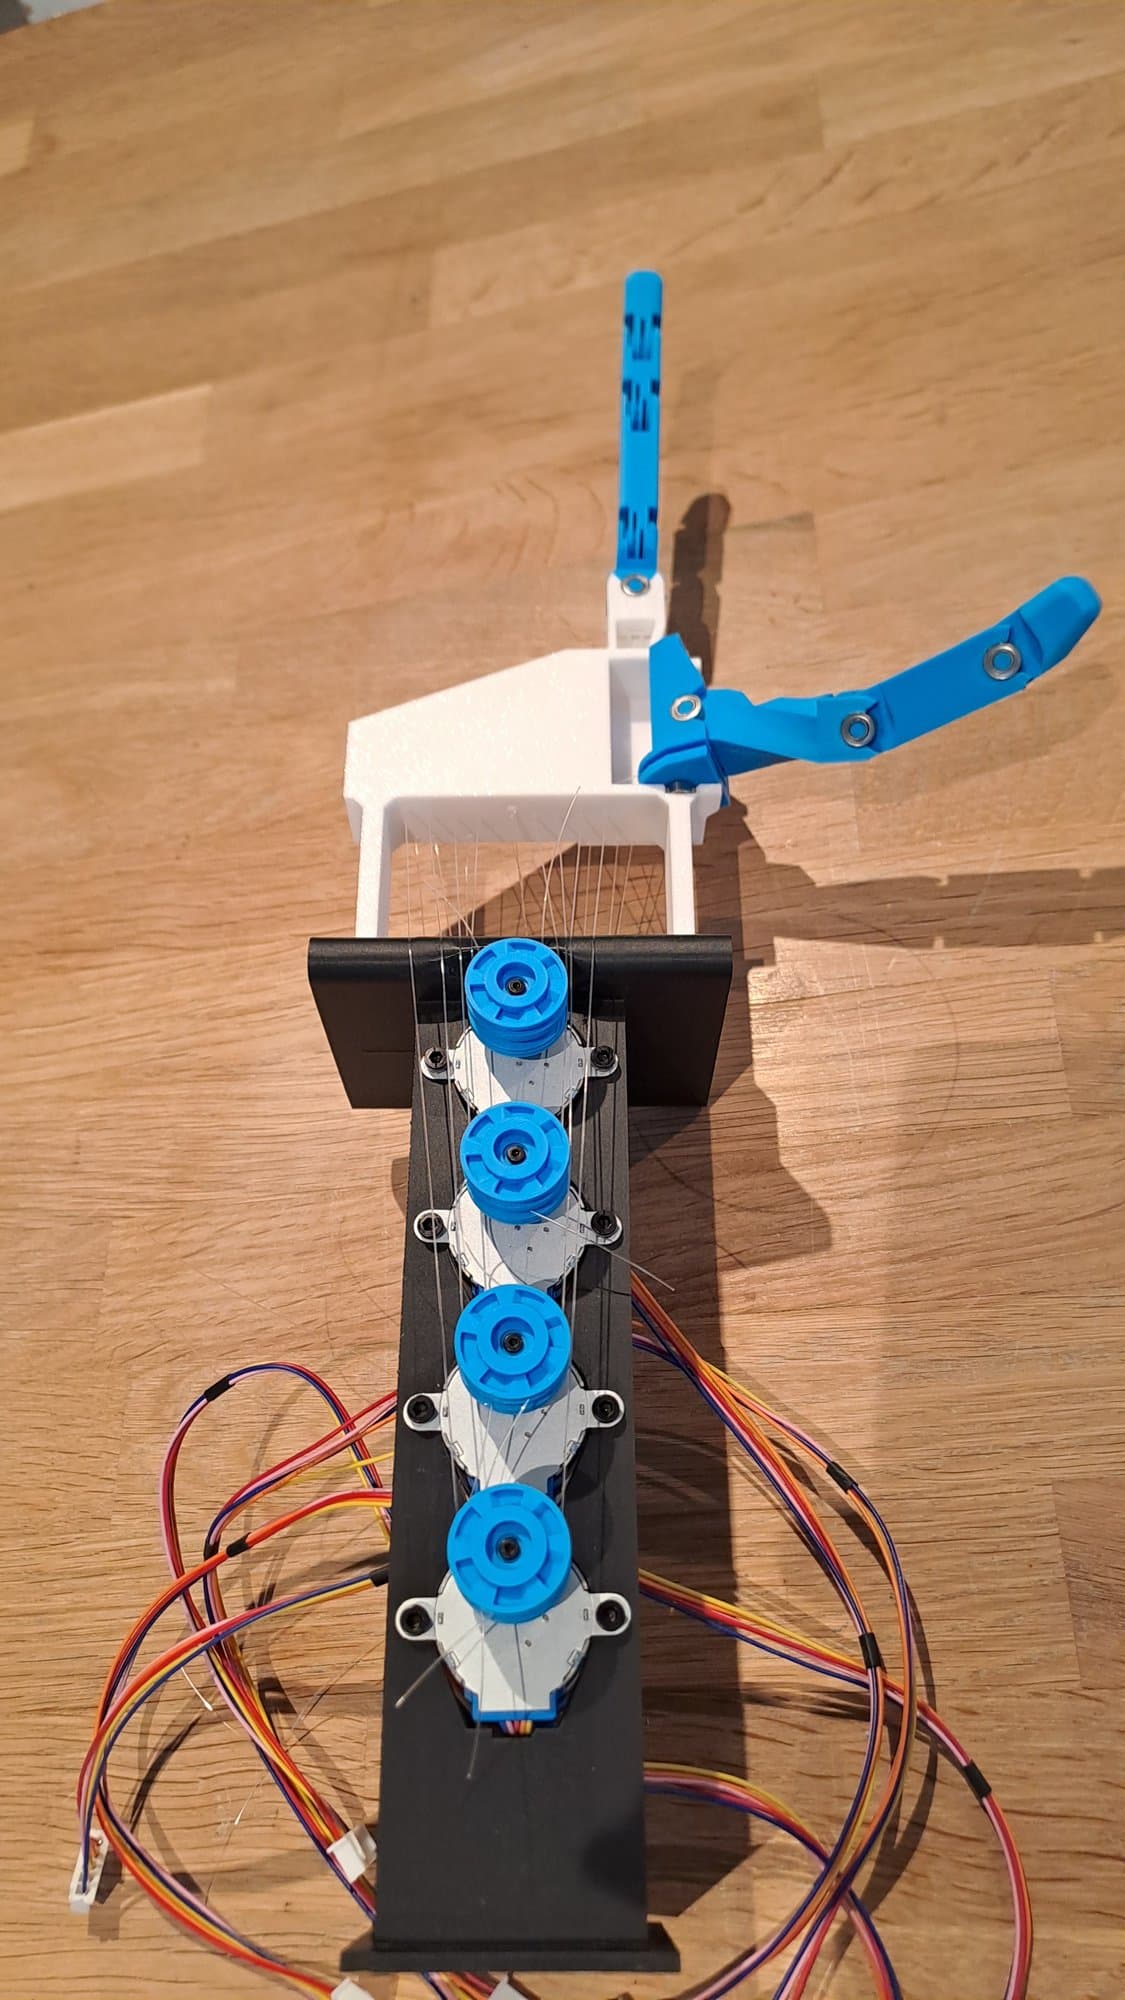
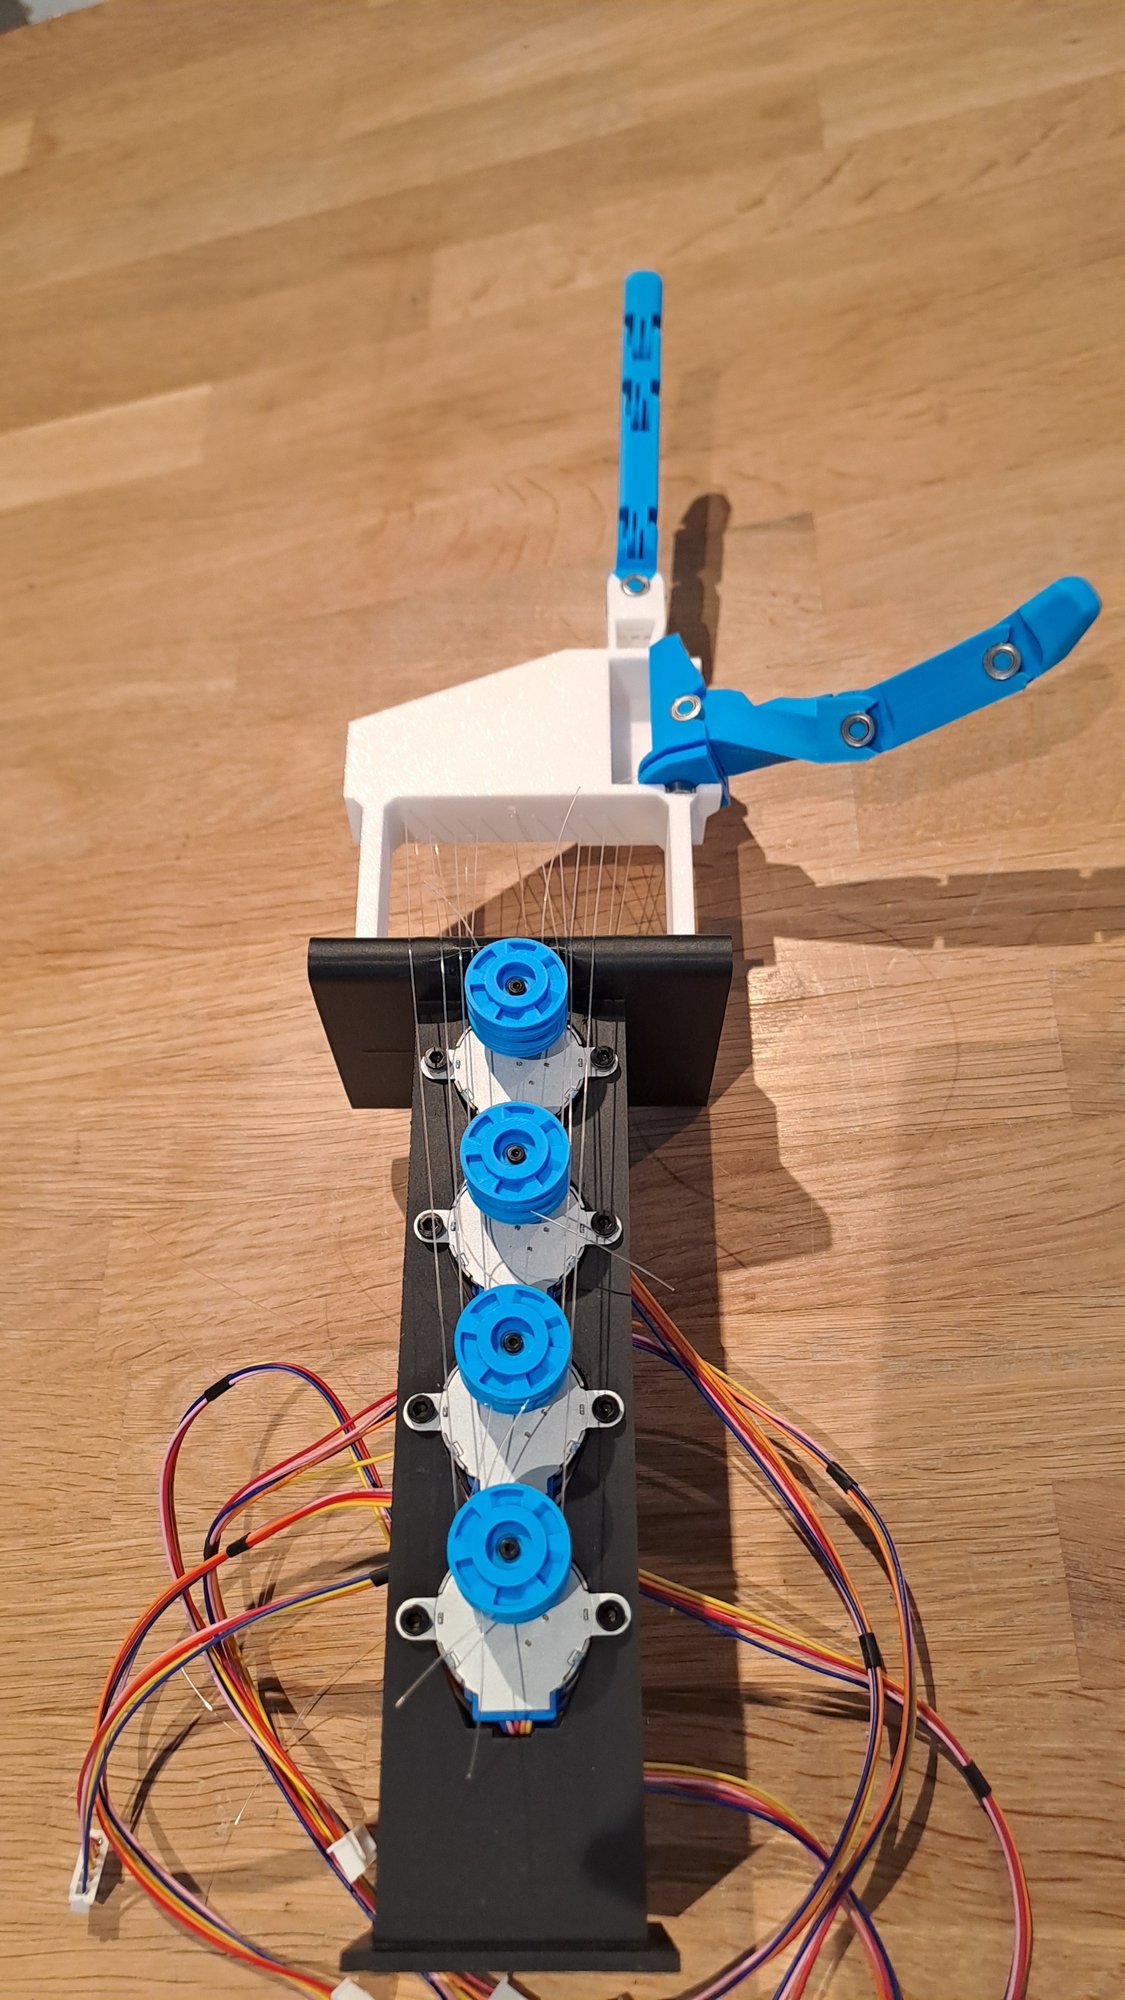
The whole V0 prototype: fingers, palm, tendons and the motor column. 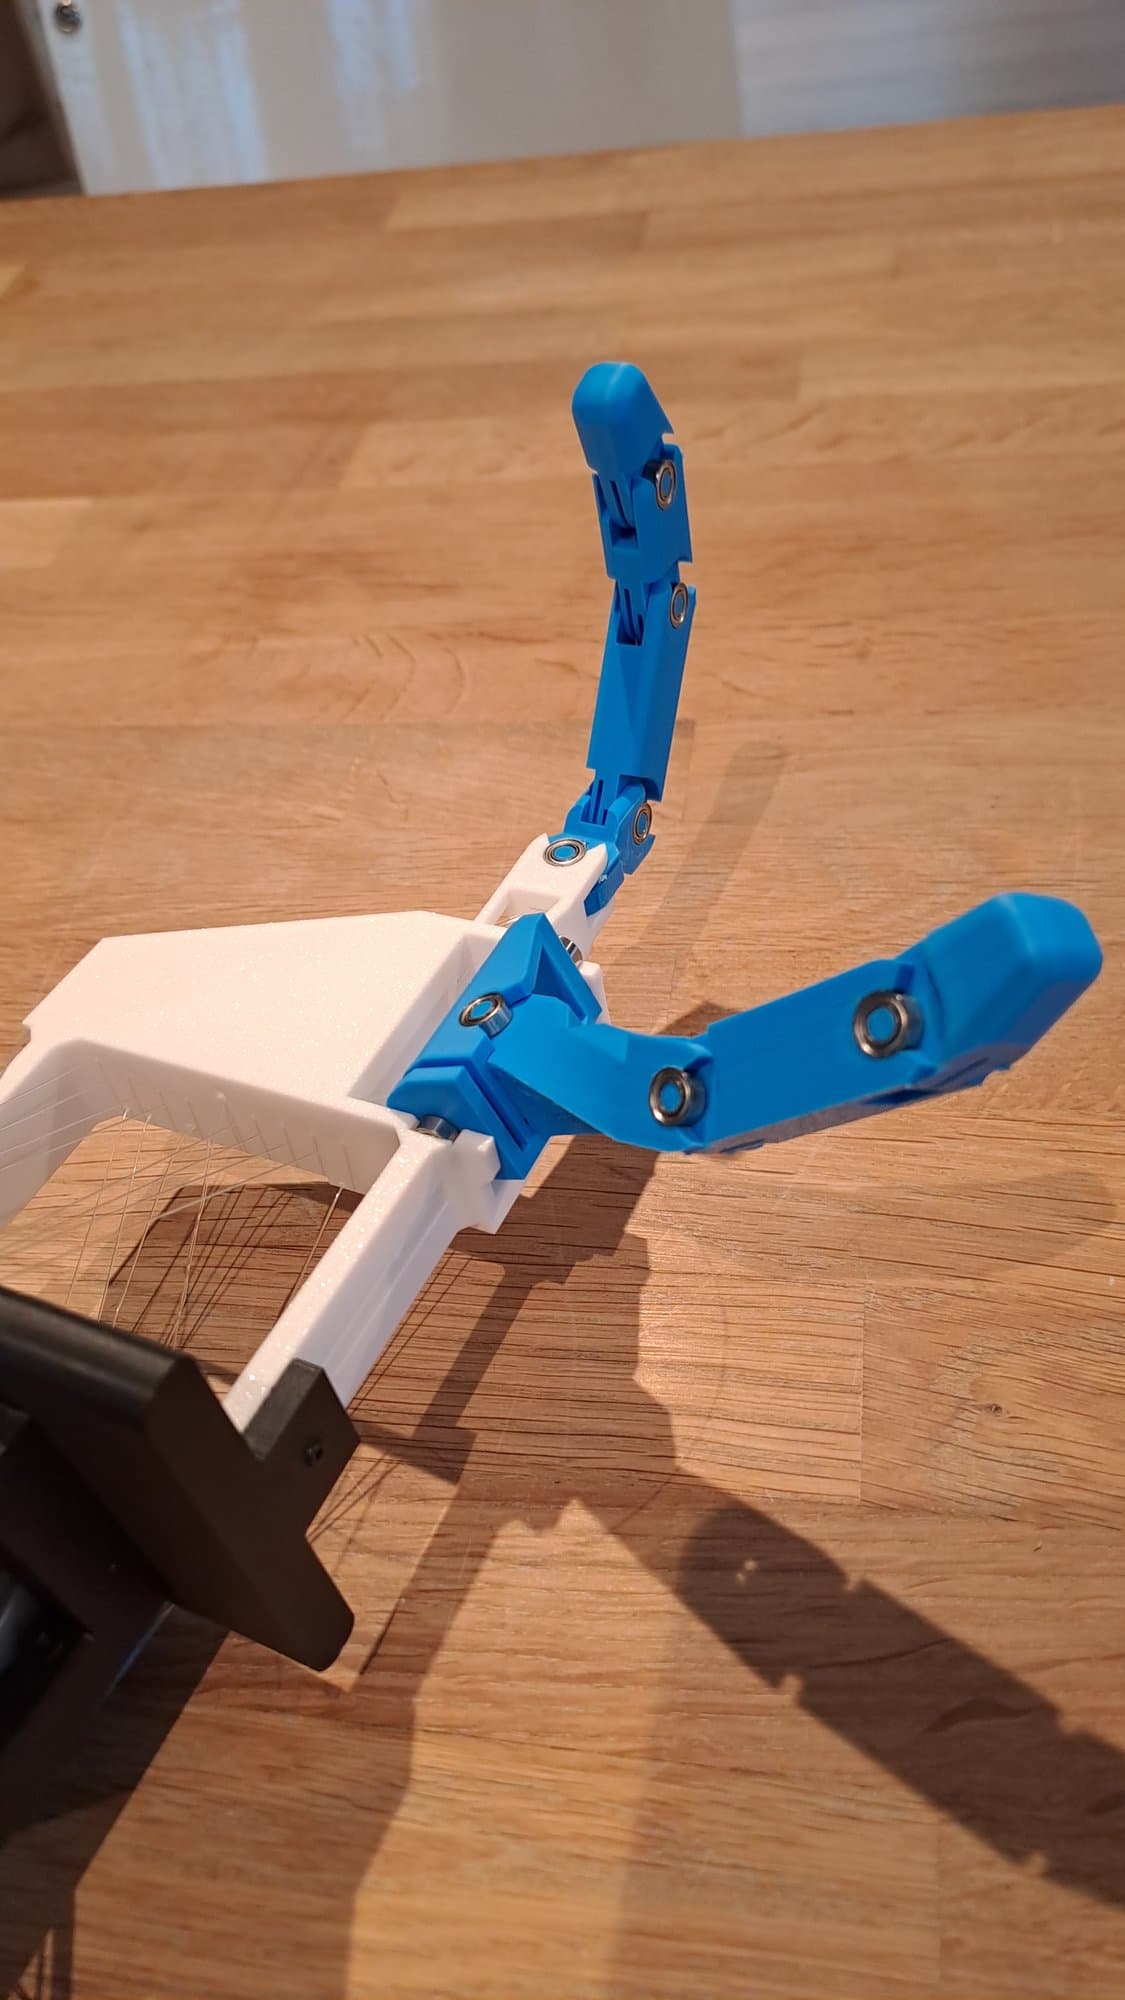
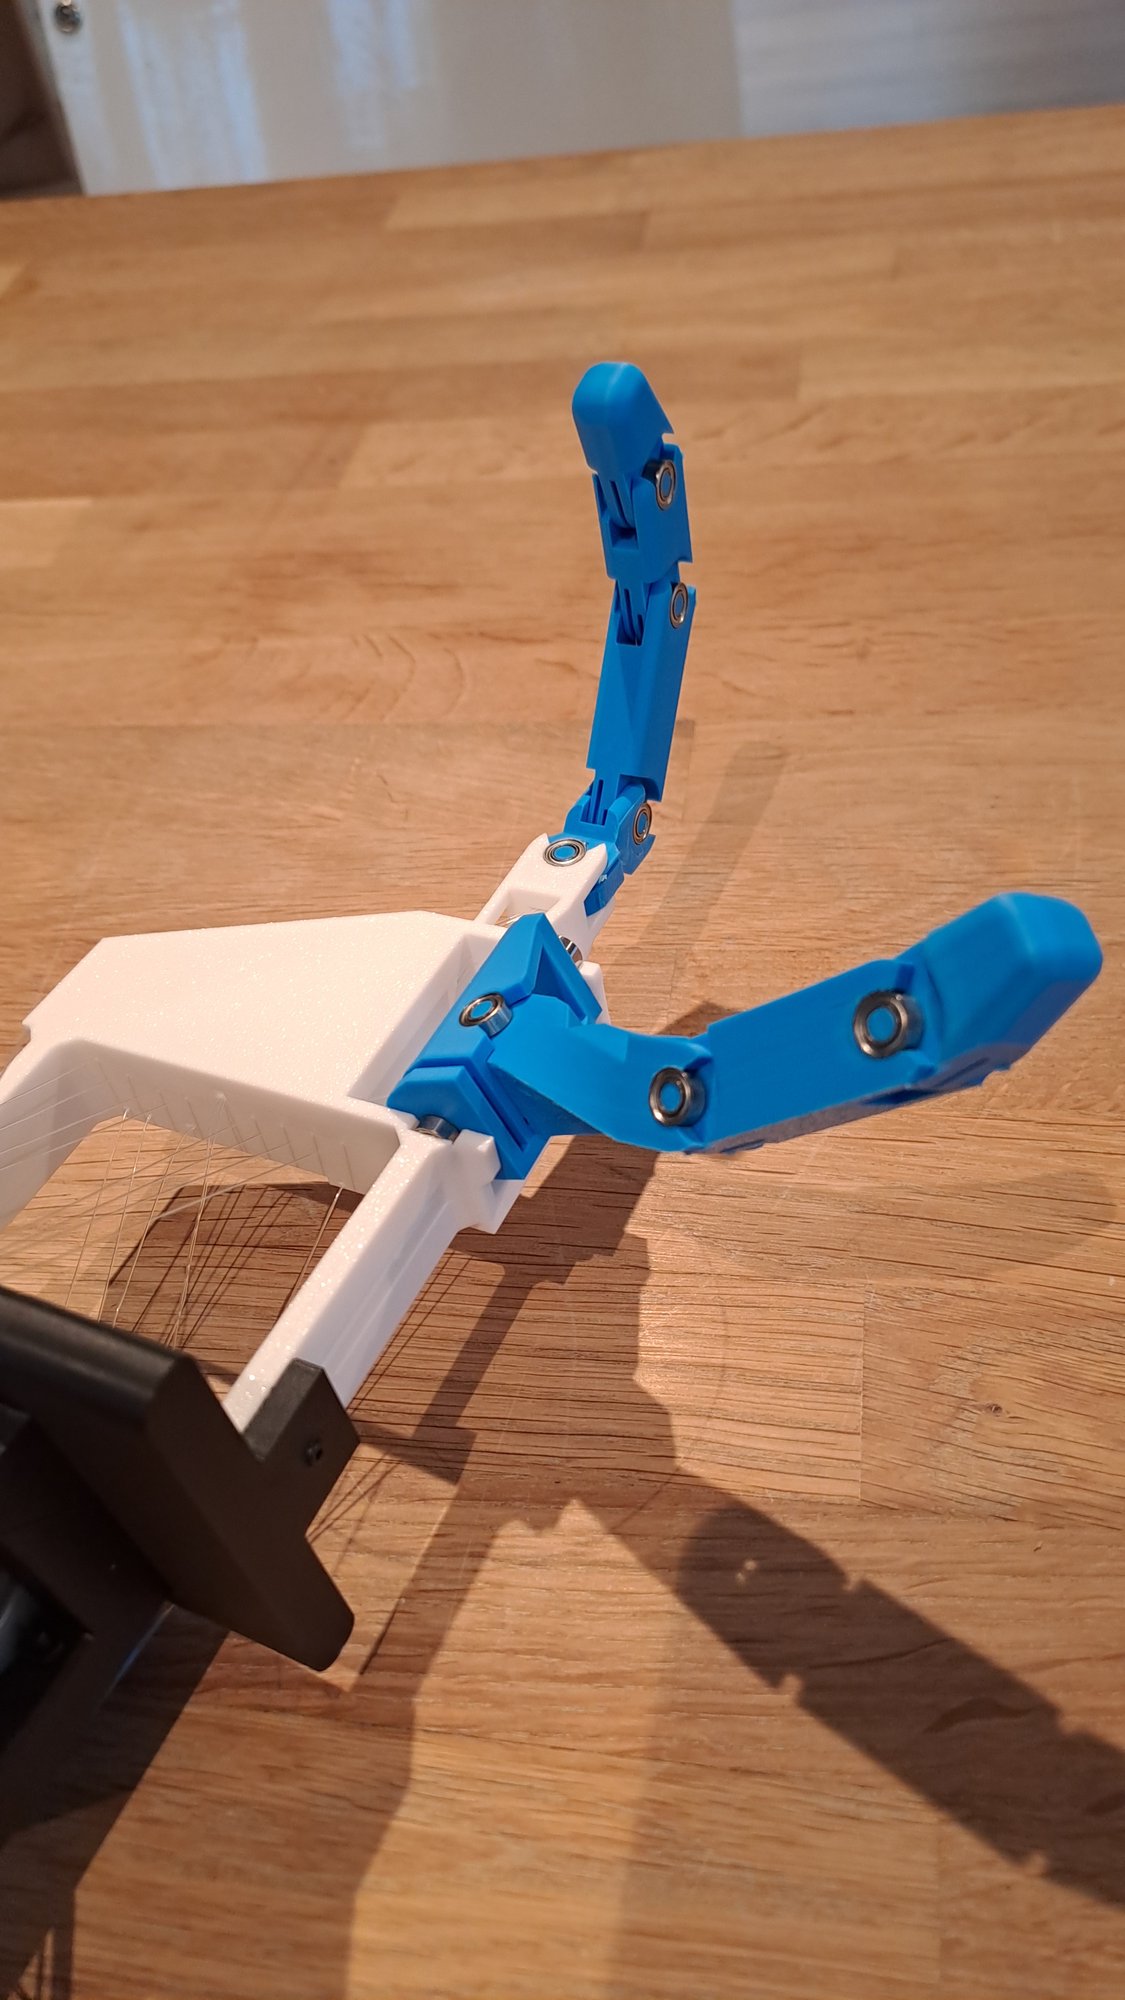
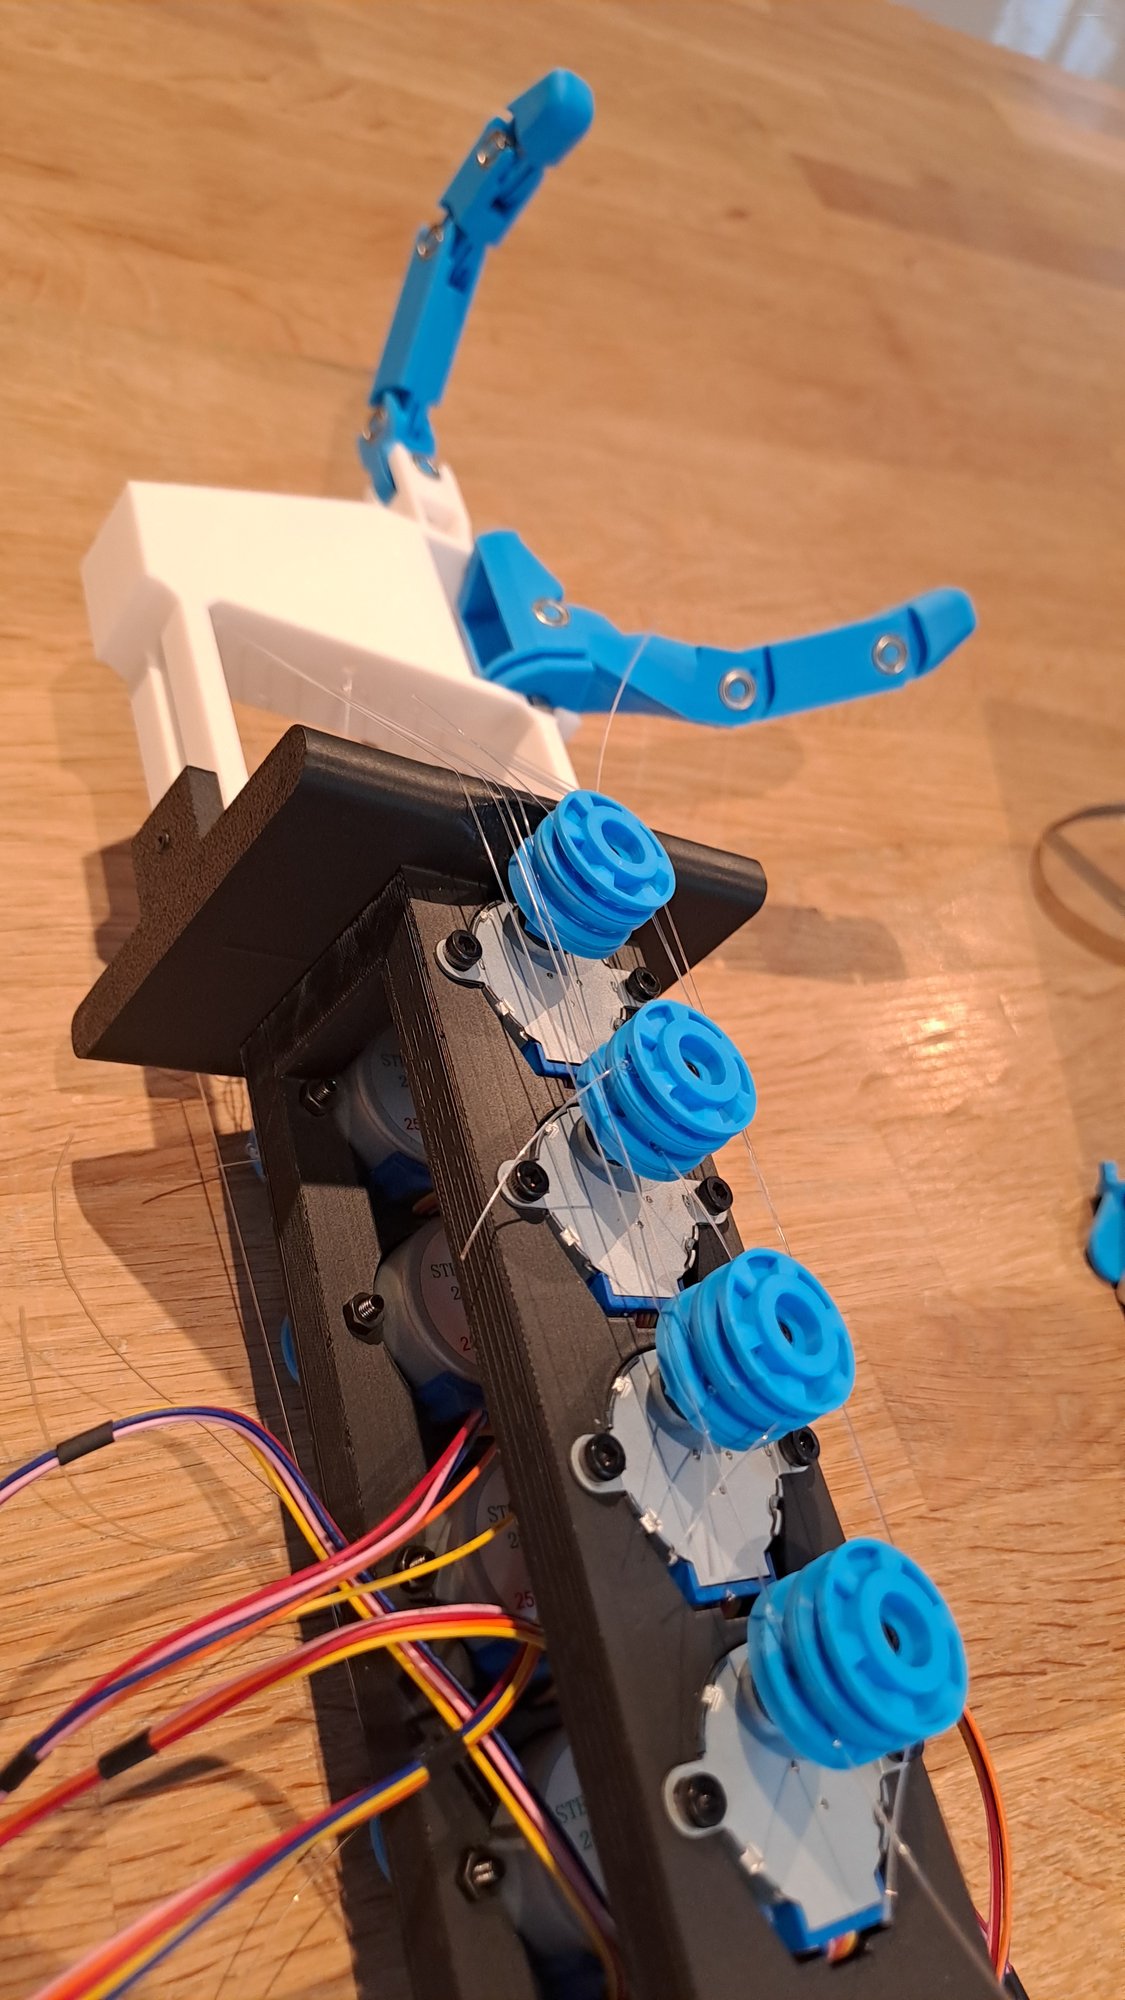
The current prototype: a thumb and an index finger with 8 joints. 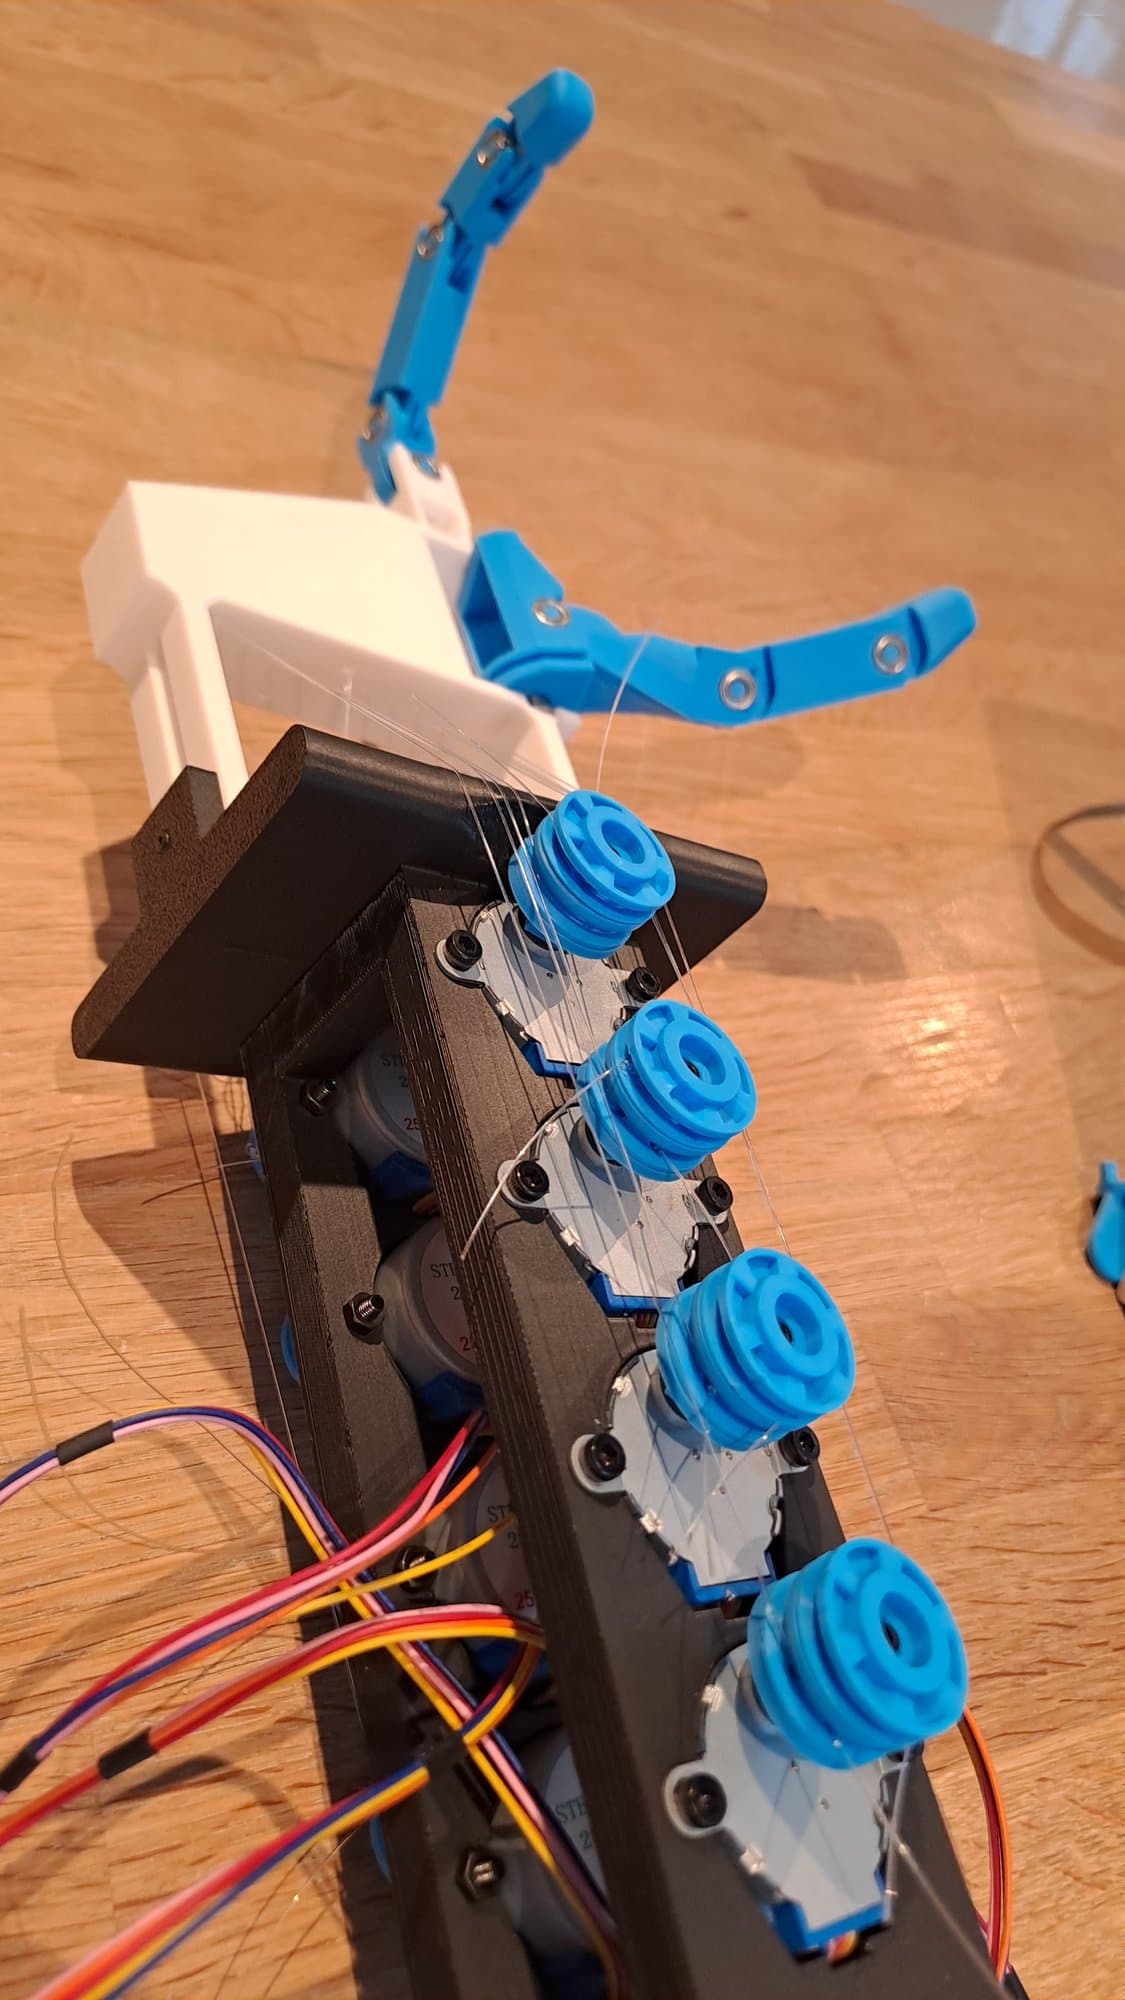
One motor and one spool per joint: each tendon loop bends the joint one way and straightens it the other. 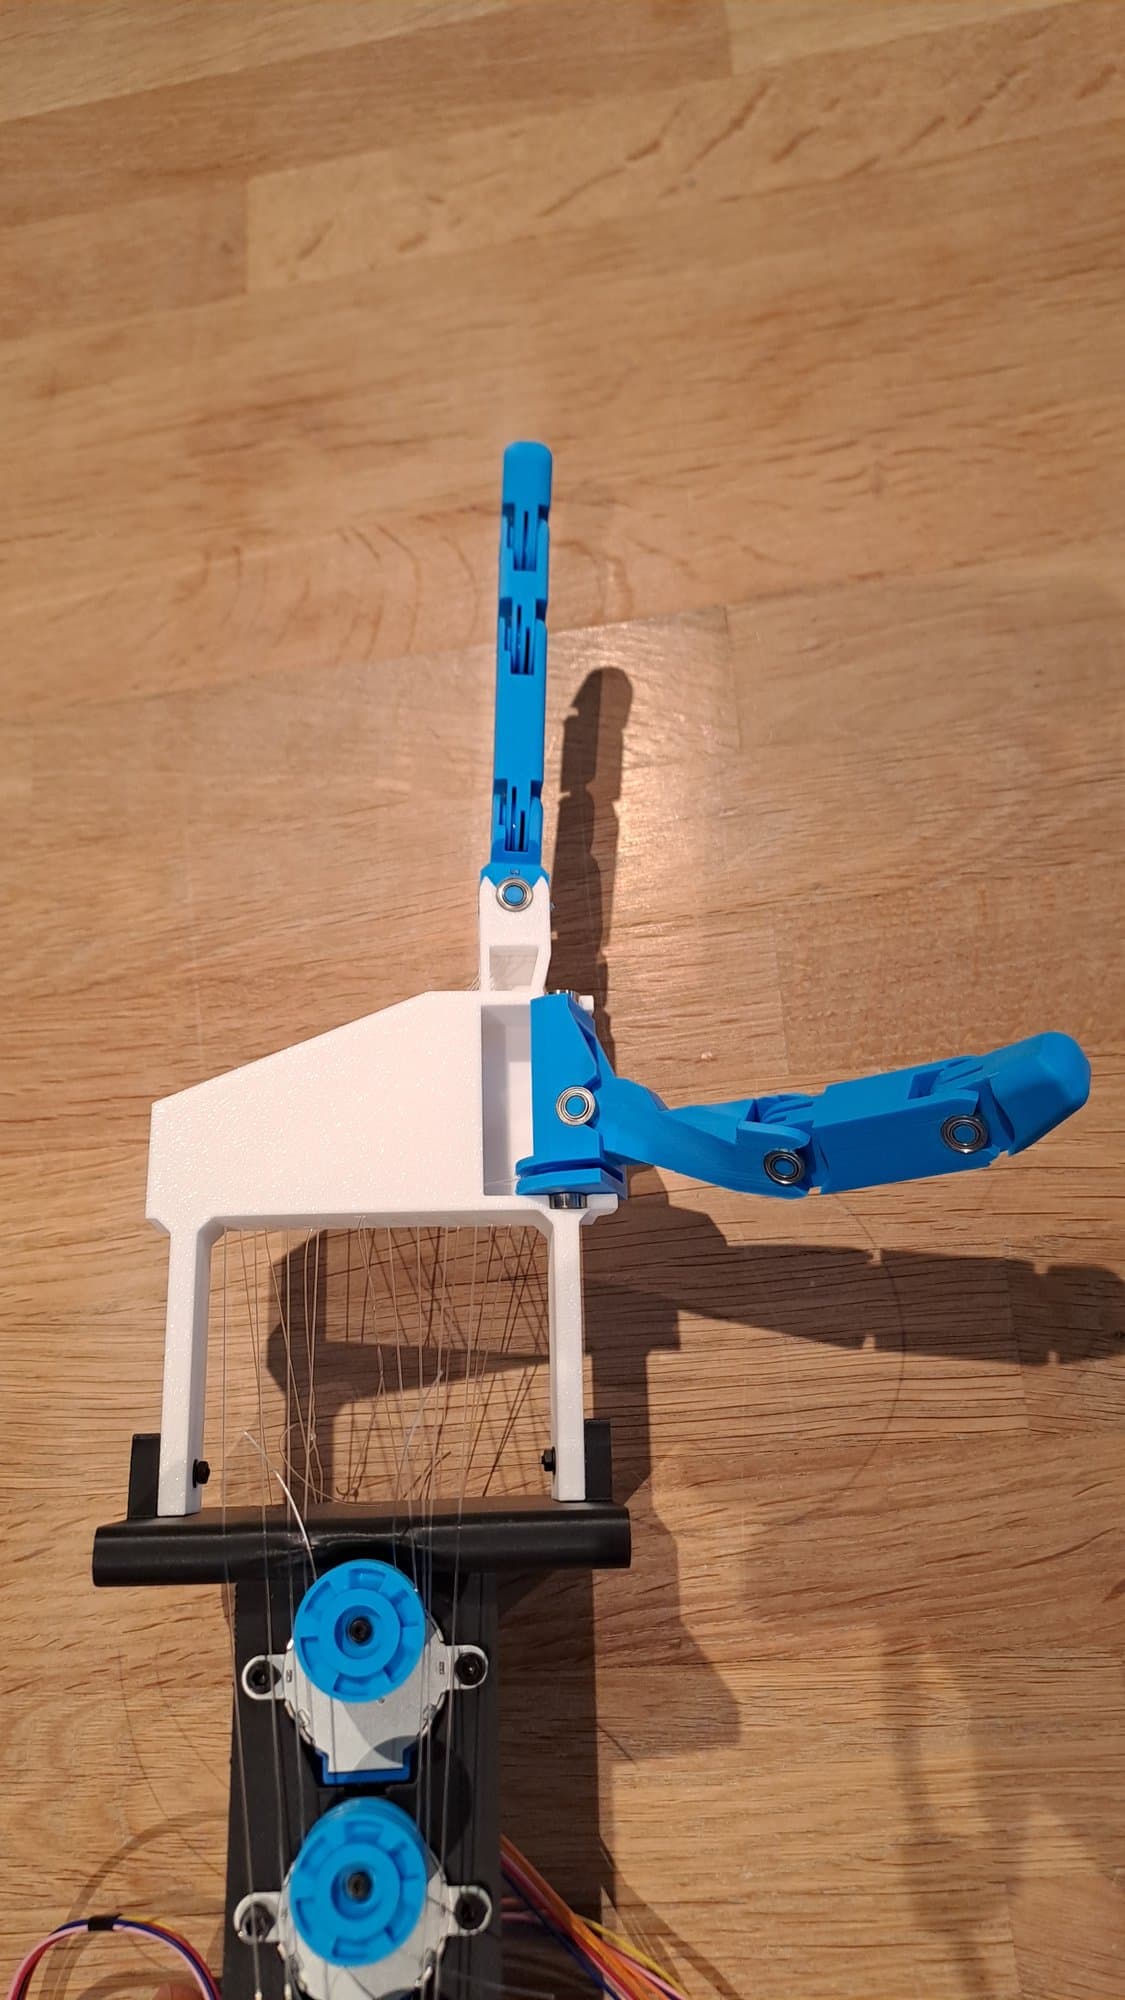
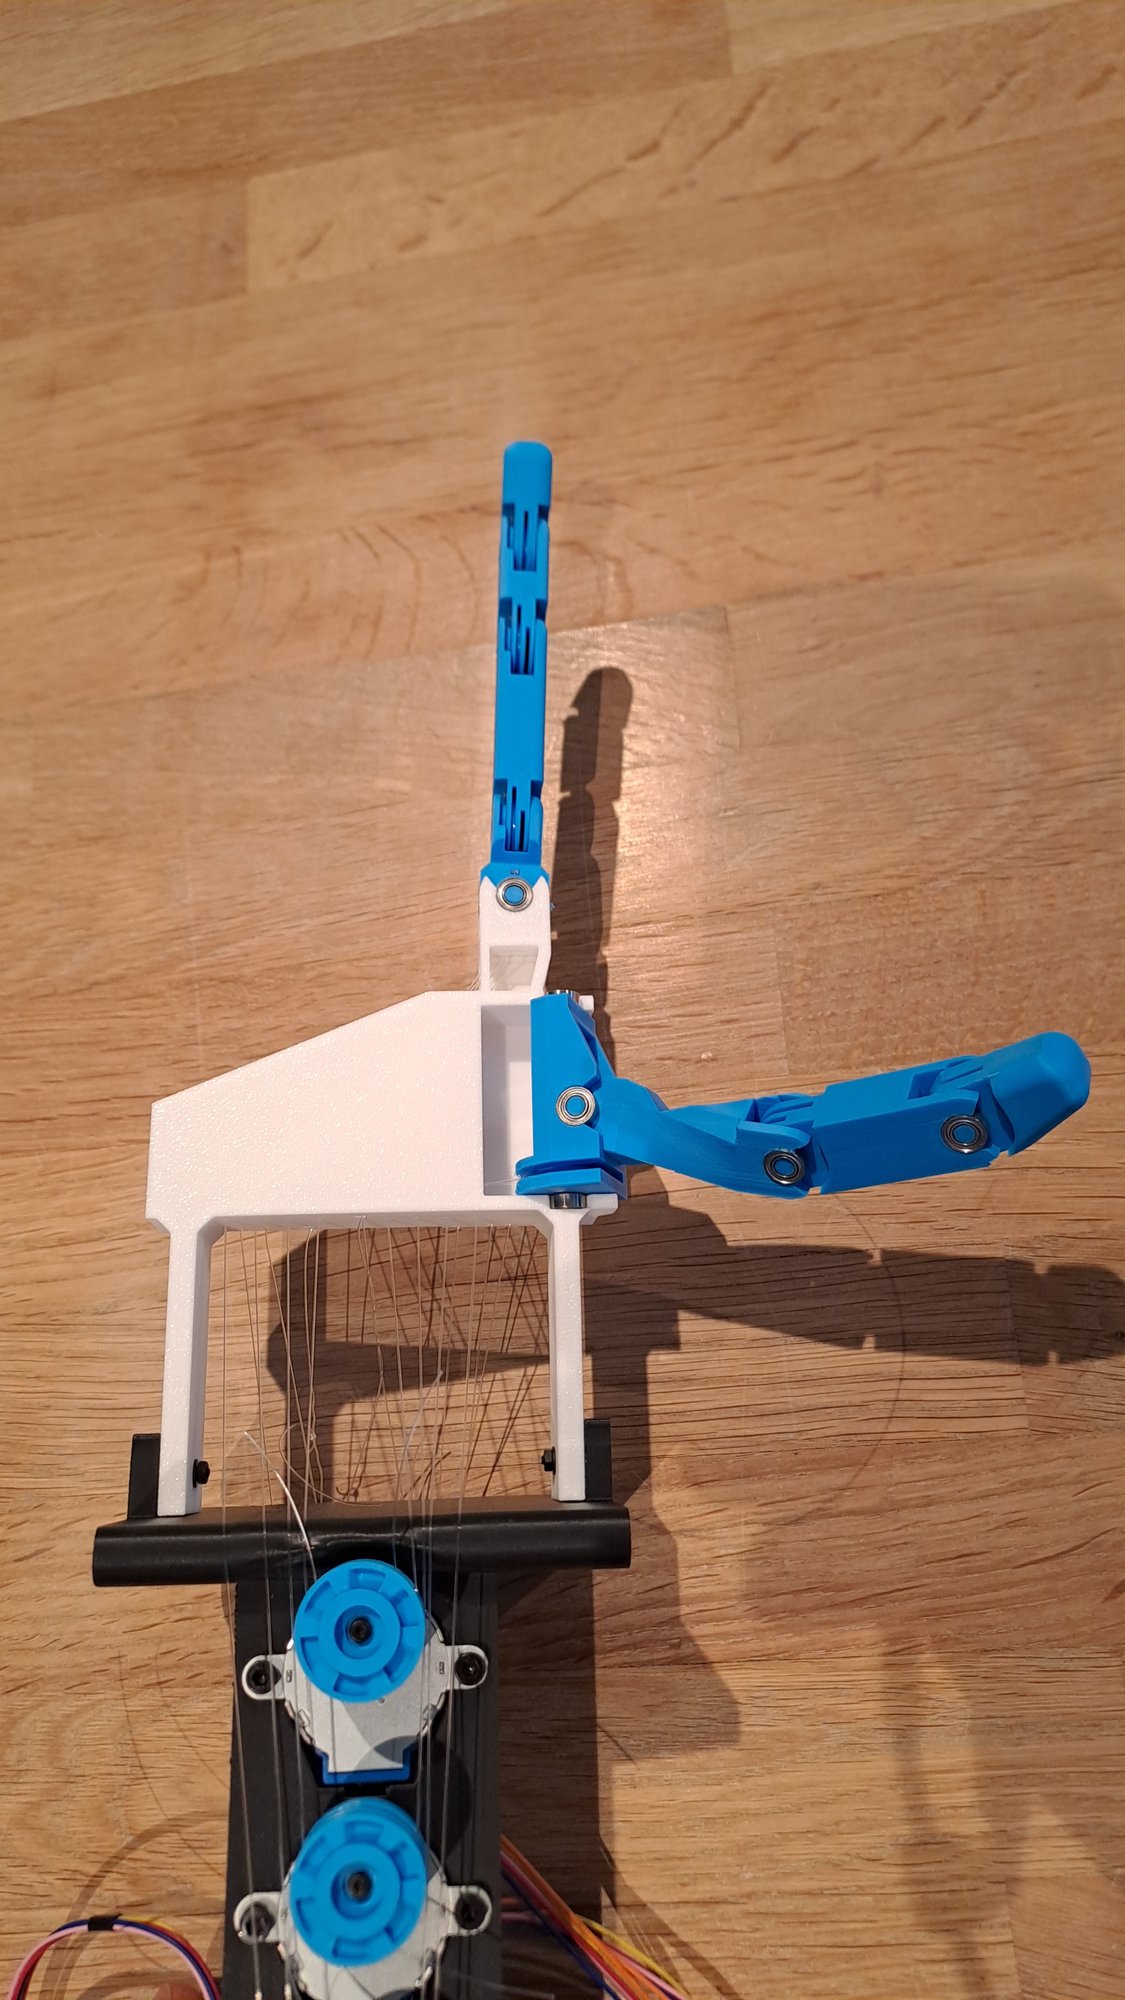
The V0 prototype from above: fingers on the palm, motors and spools below. 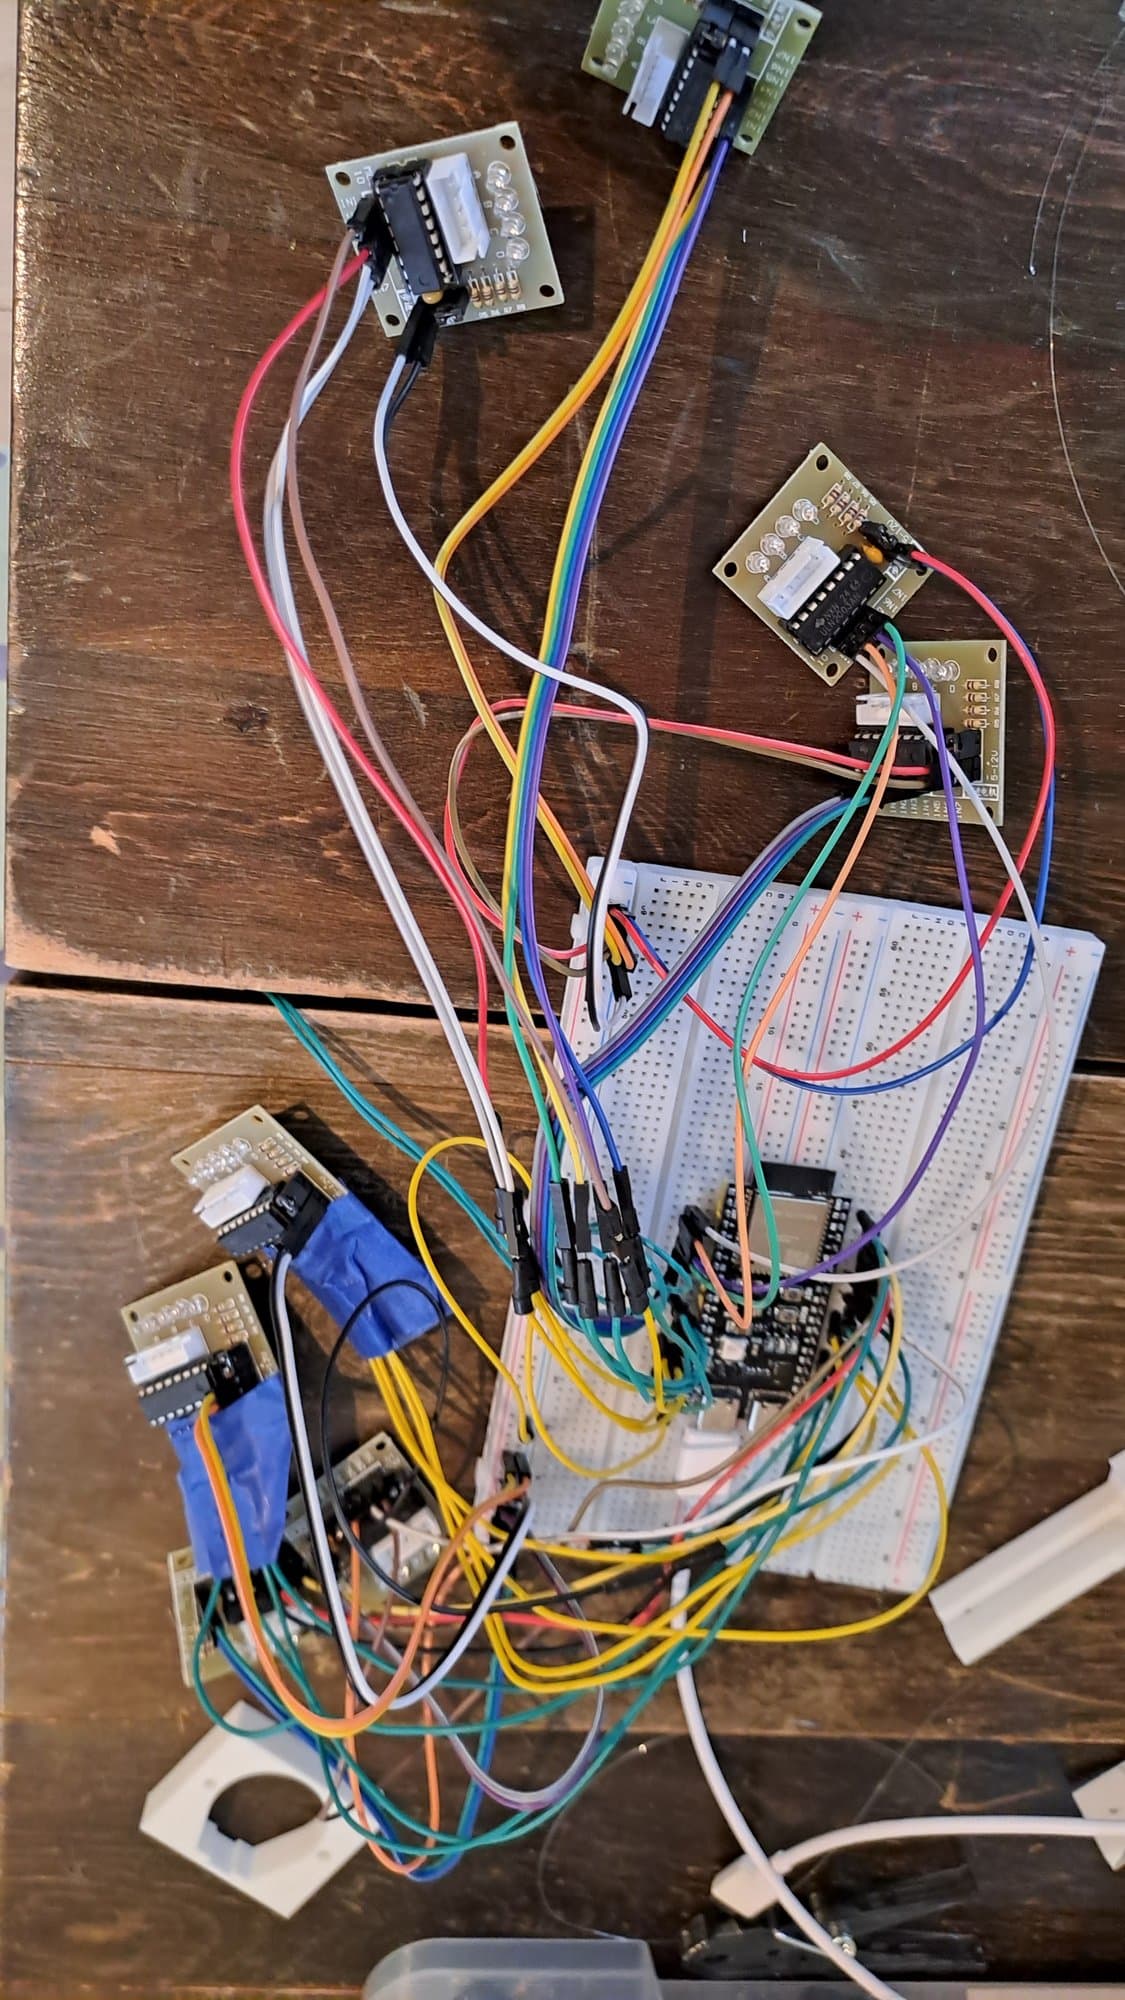
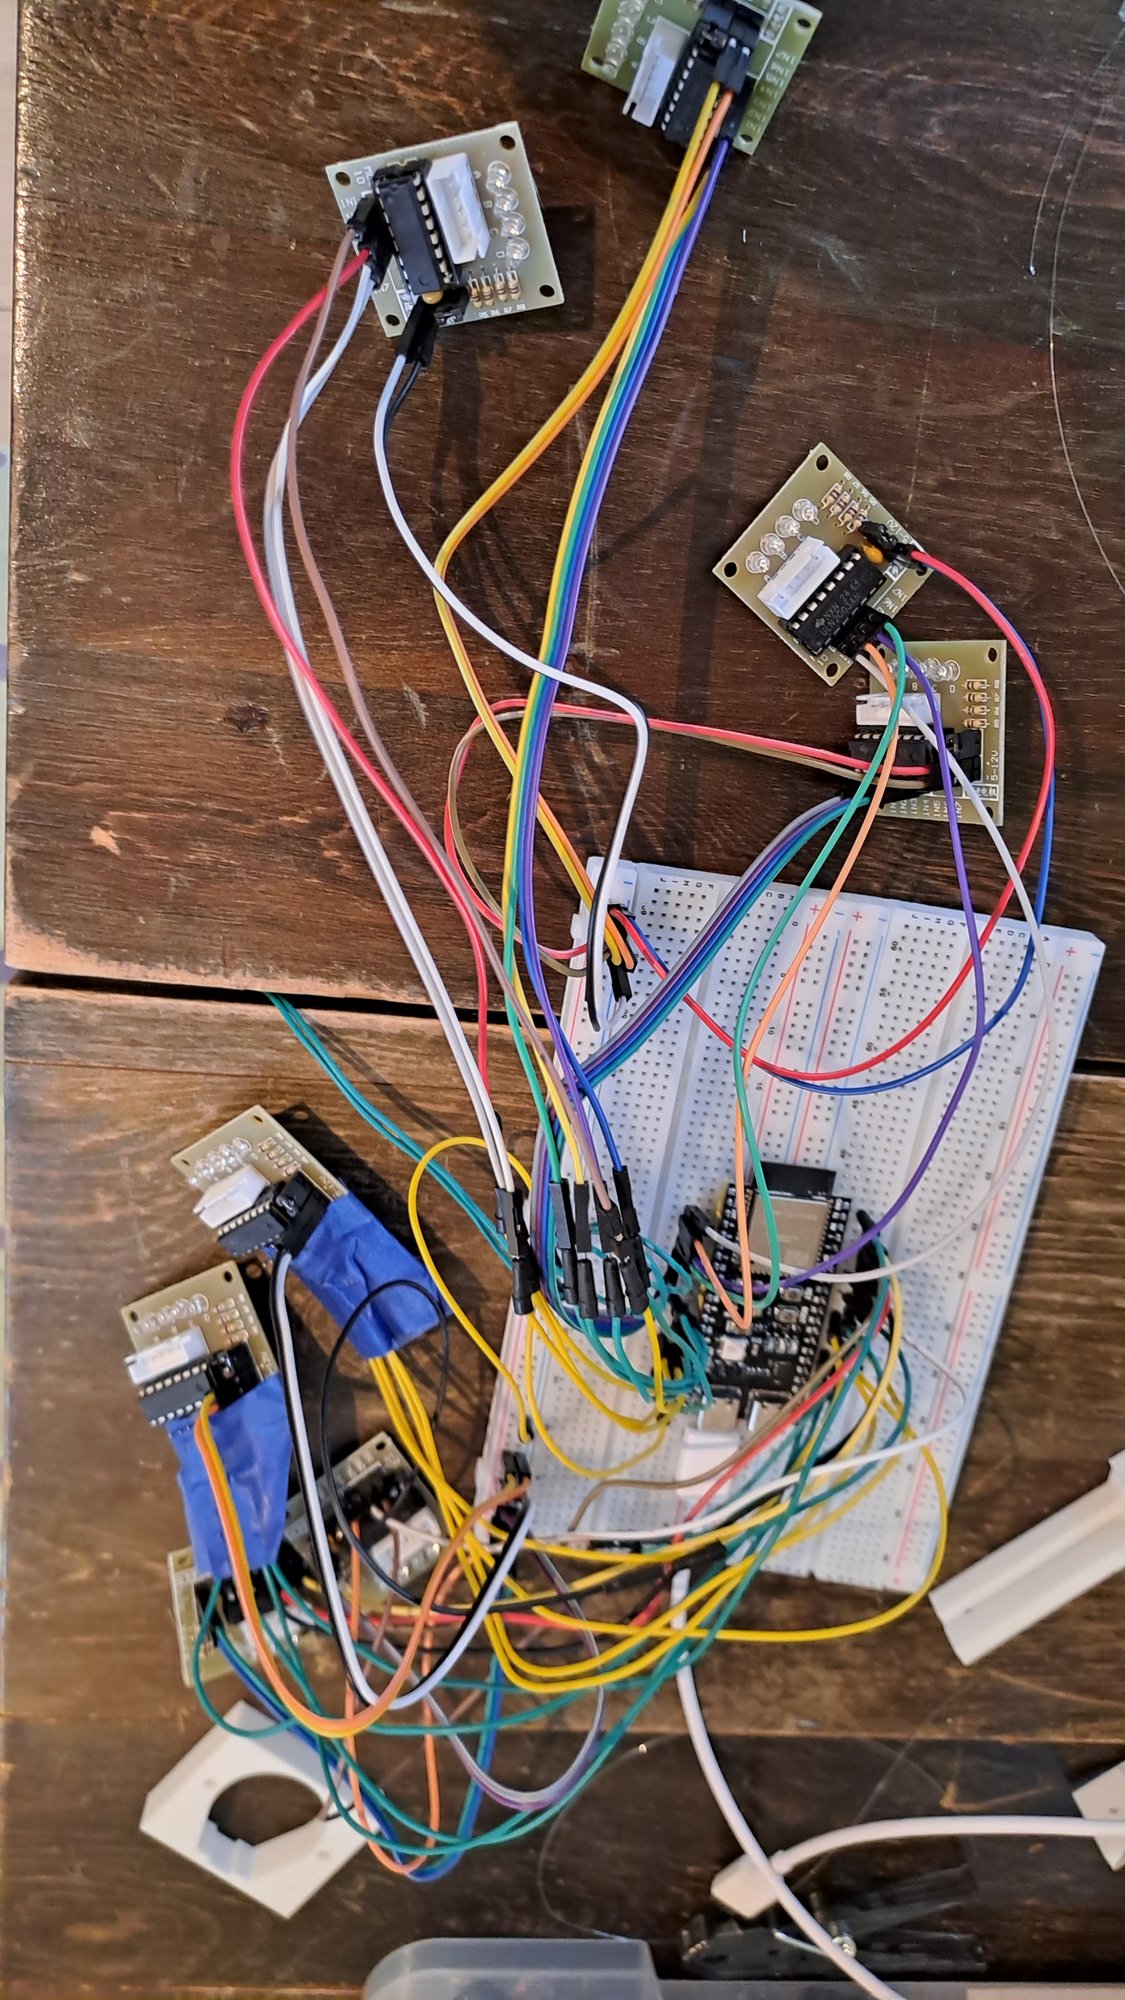
The electronics: one ESP32-S3 and a driver board for each of the 8 motors. 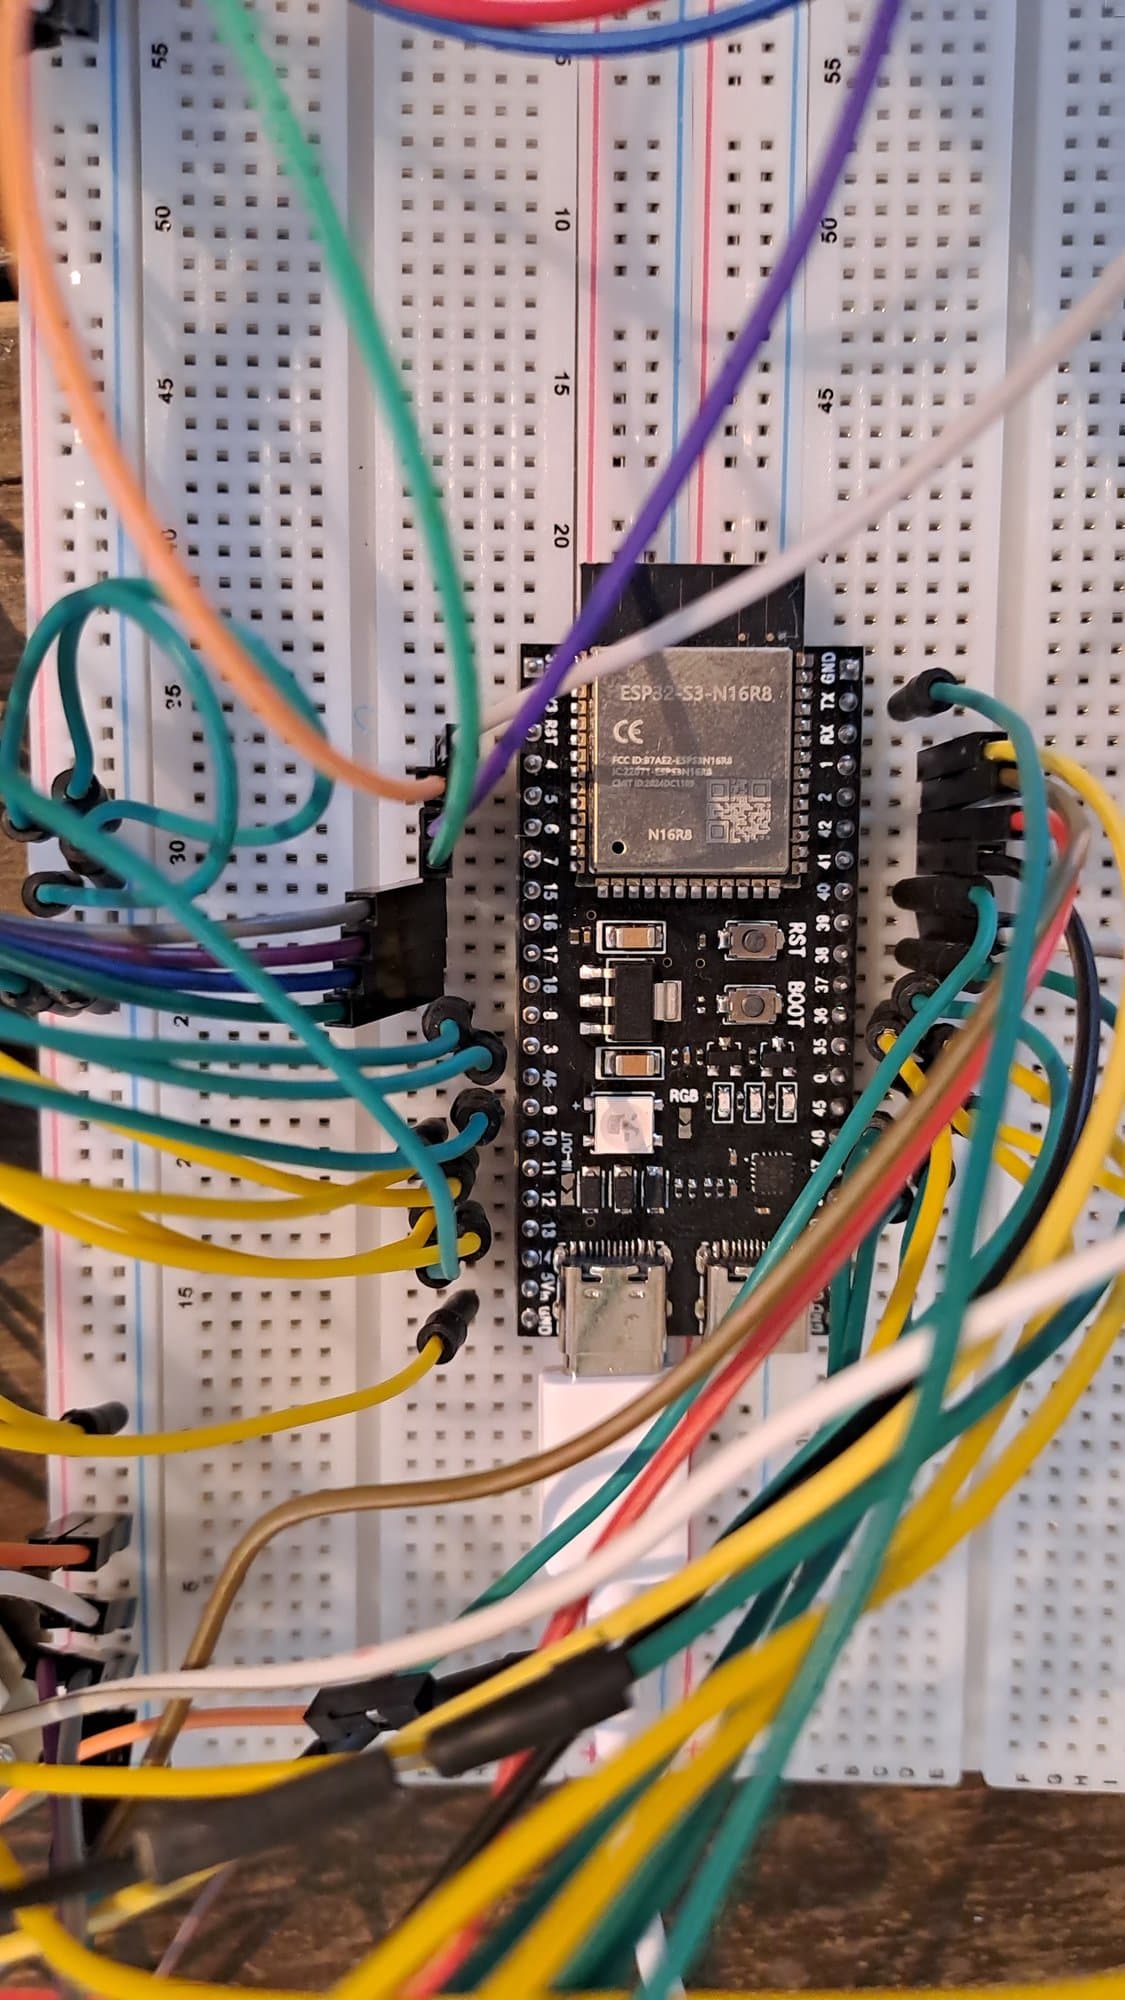
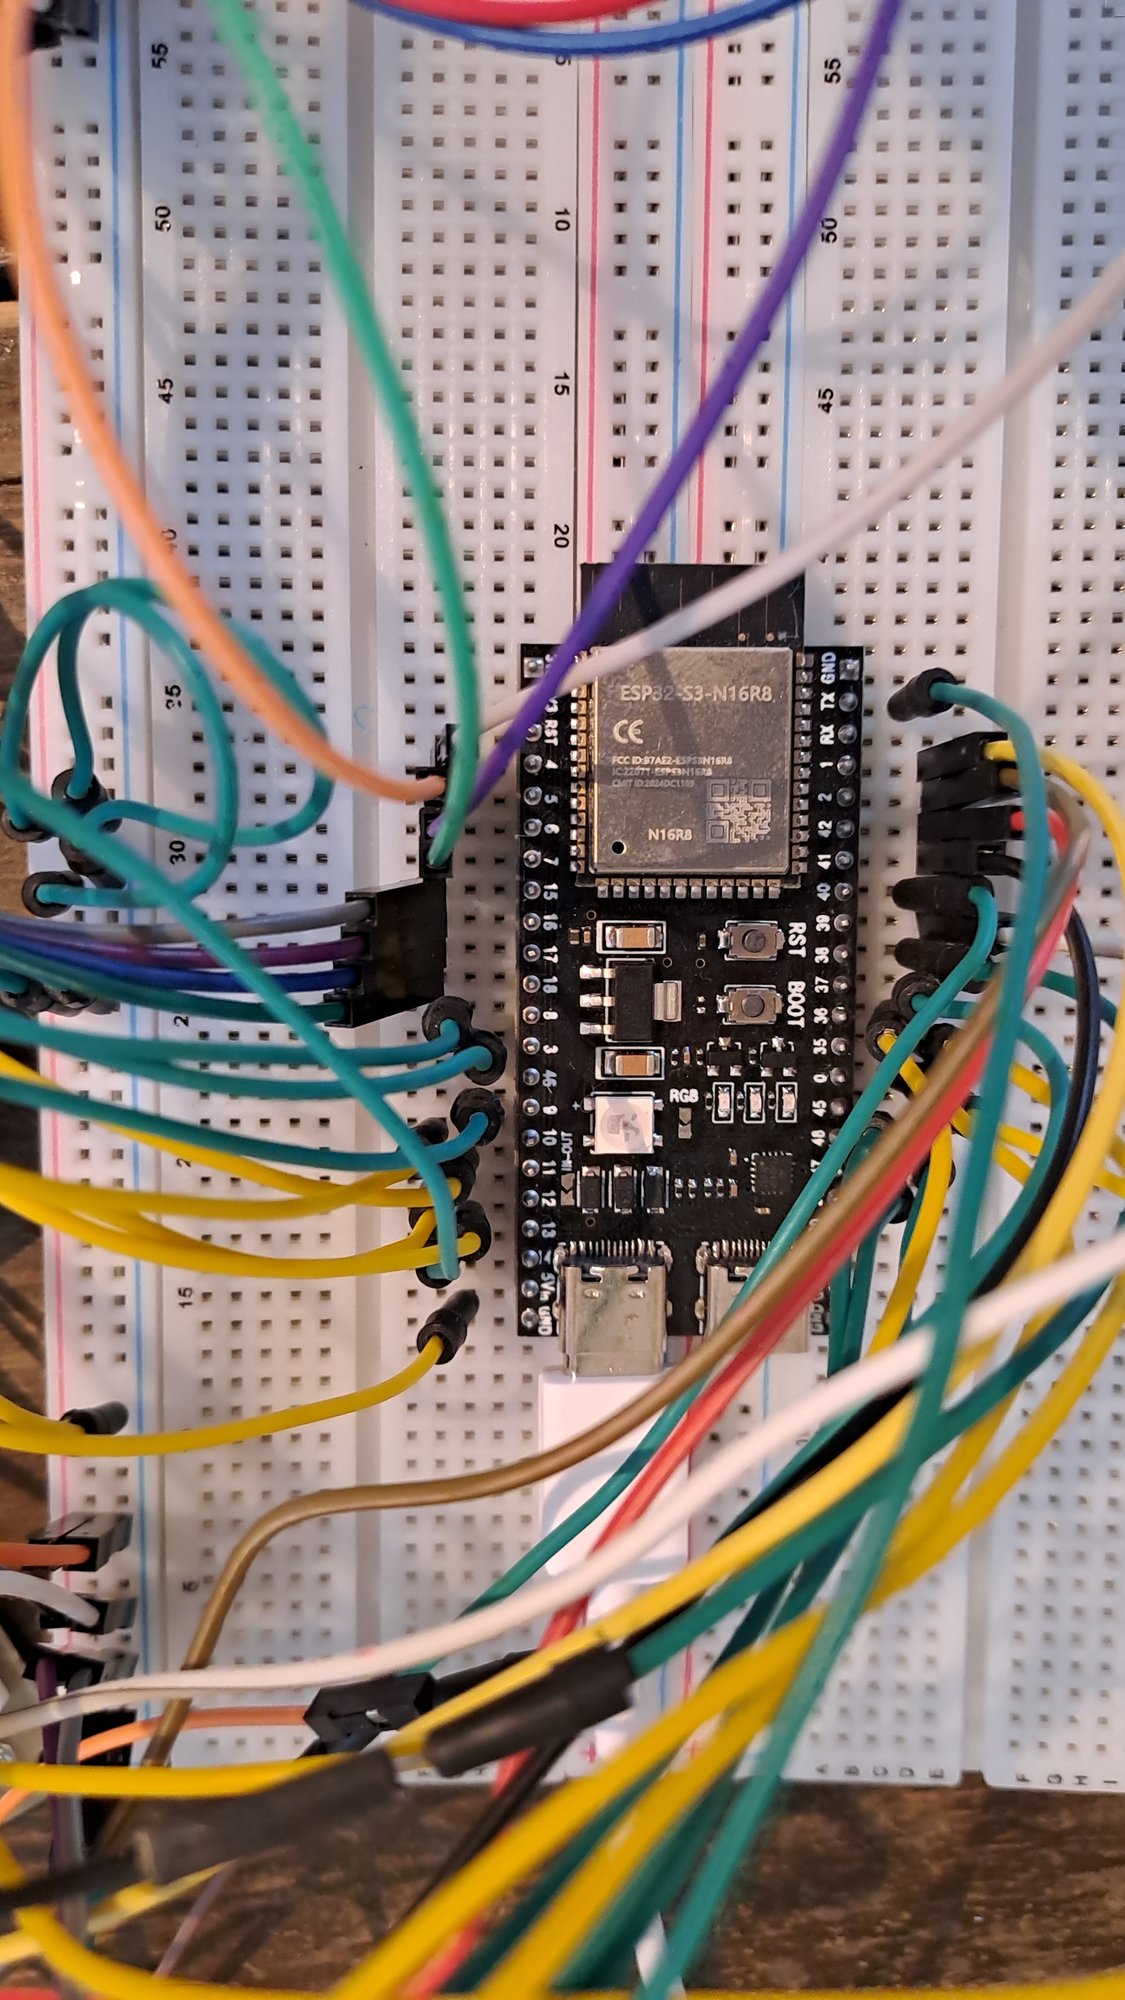
The ESP32-S3 controller, the brain of the prototype. 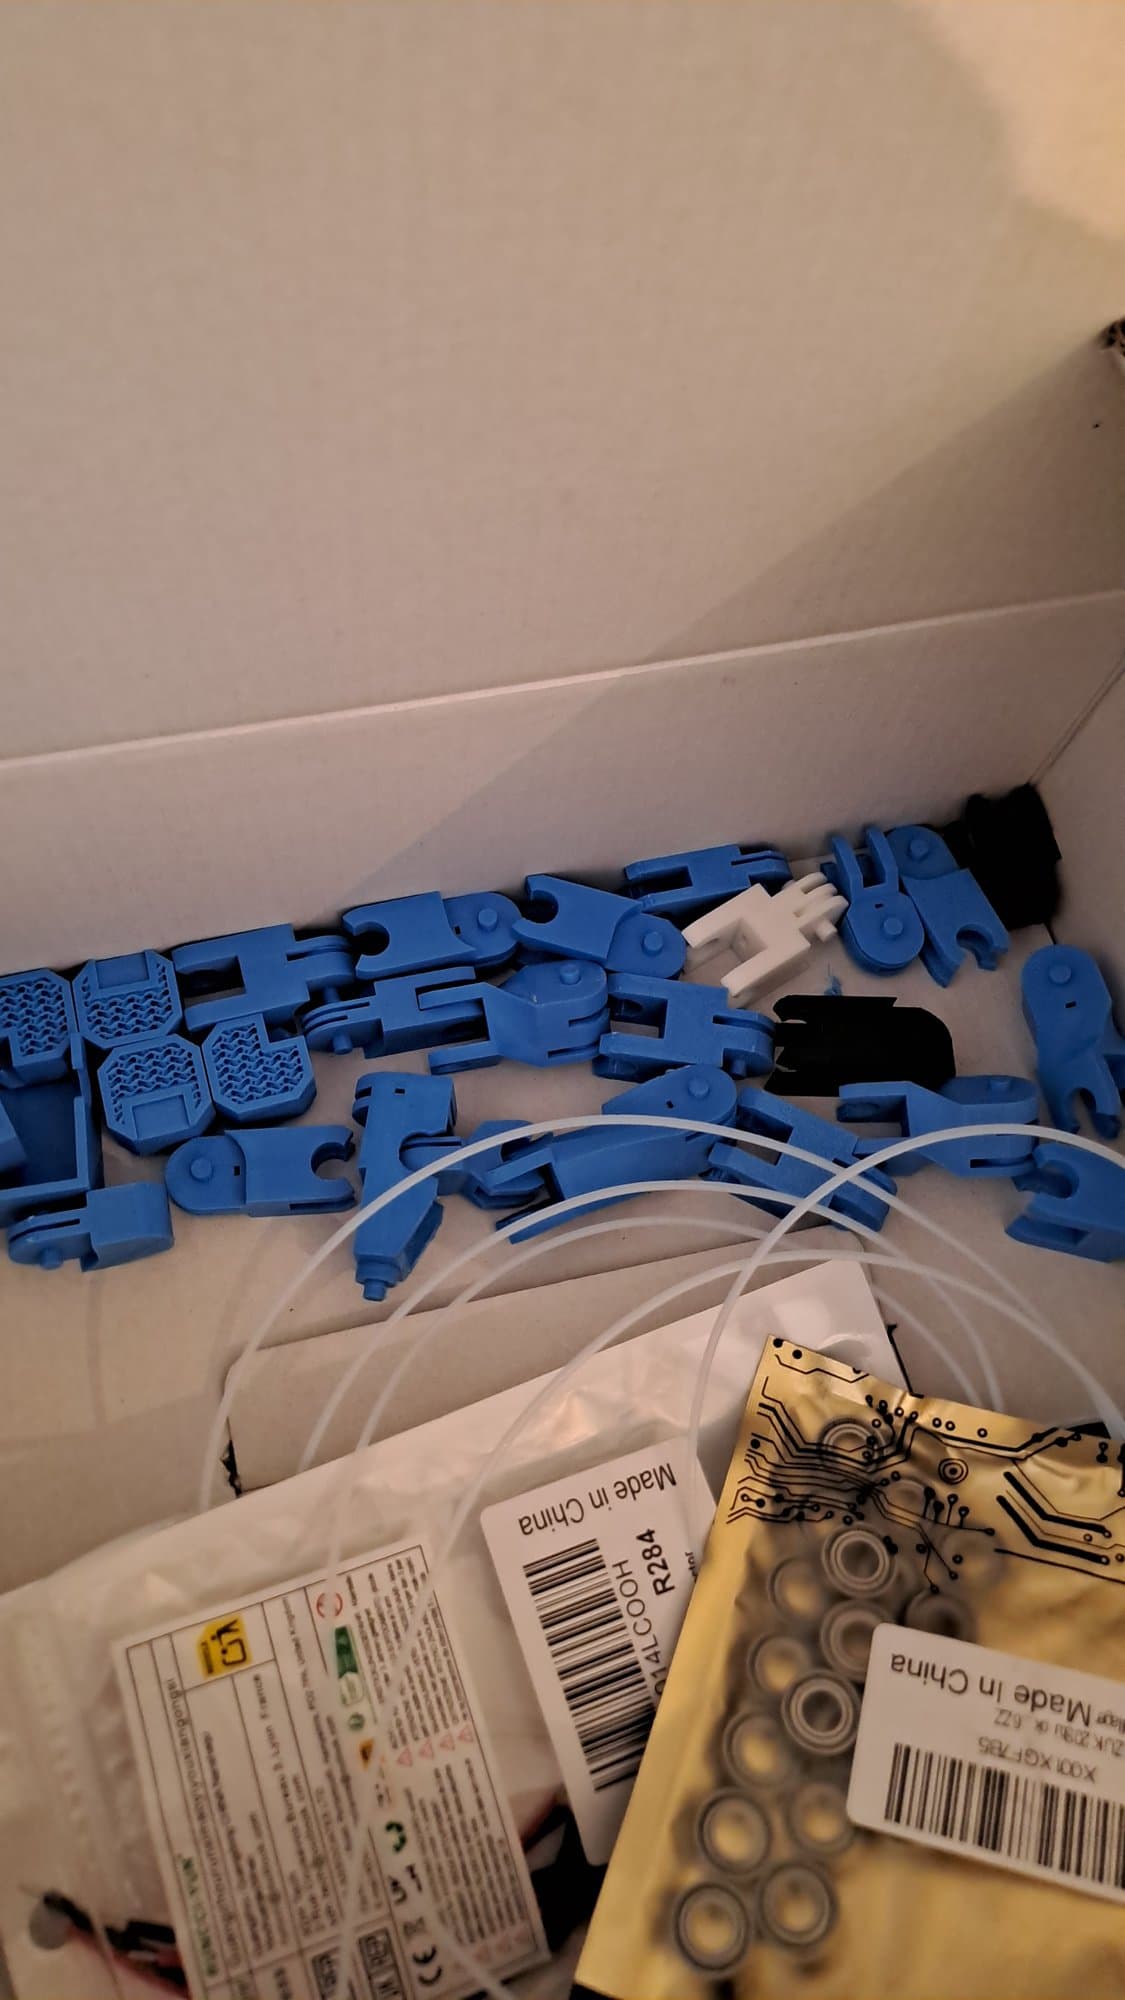
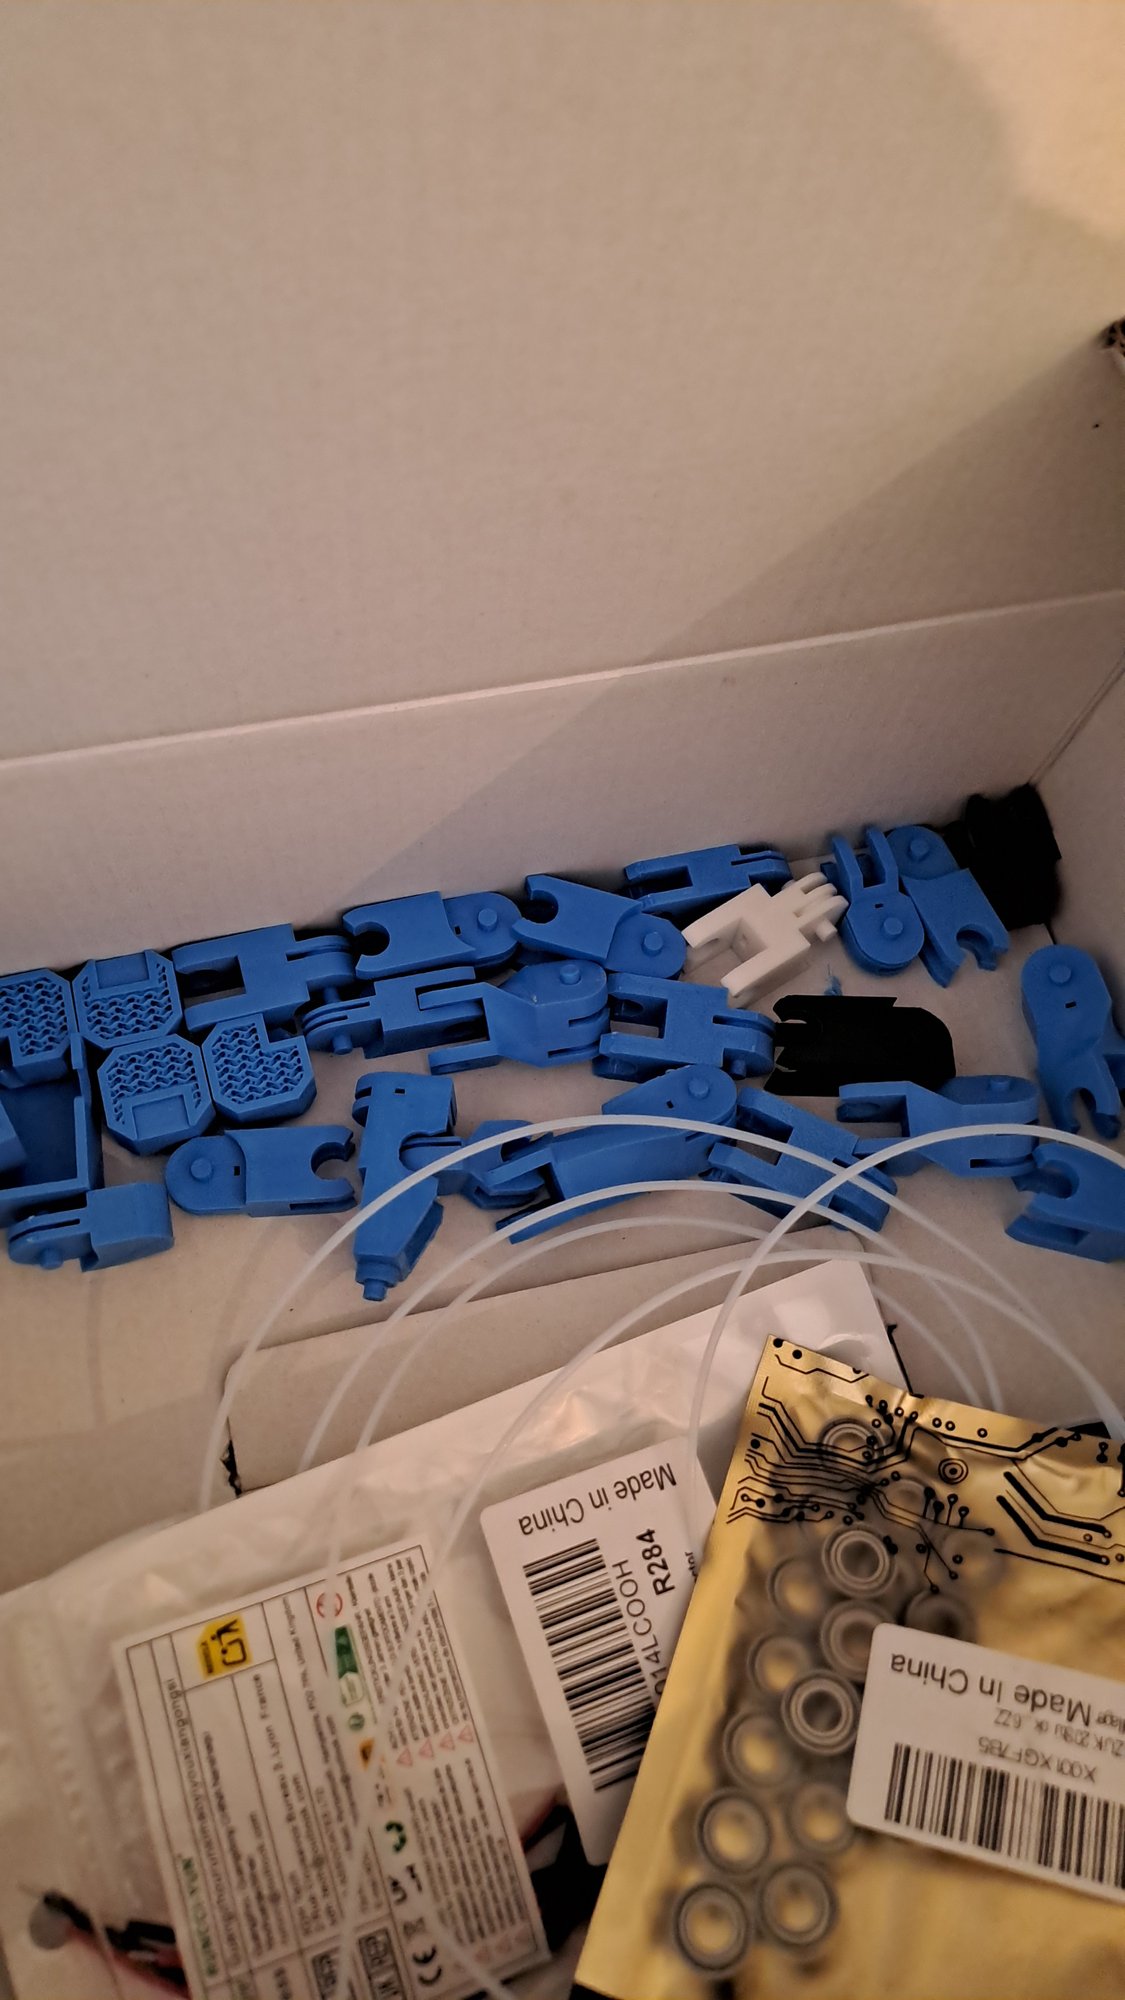
Every part of the skeleton comes off an ordinary 3D printer. 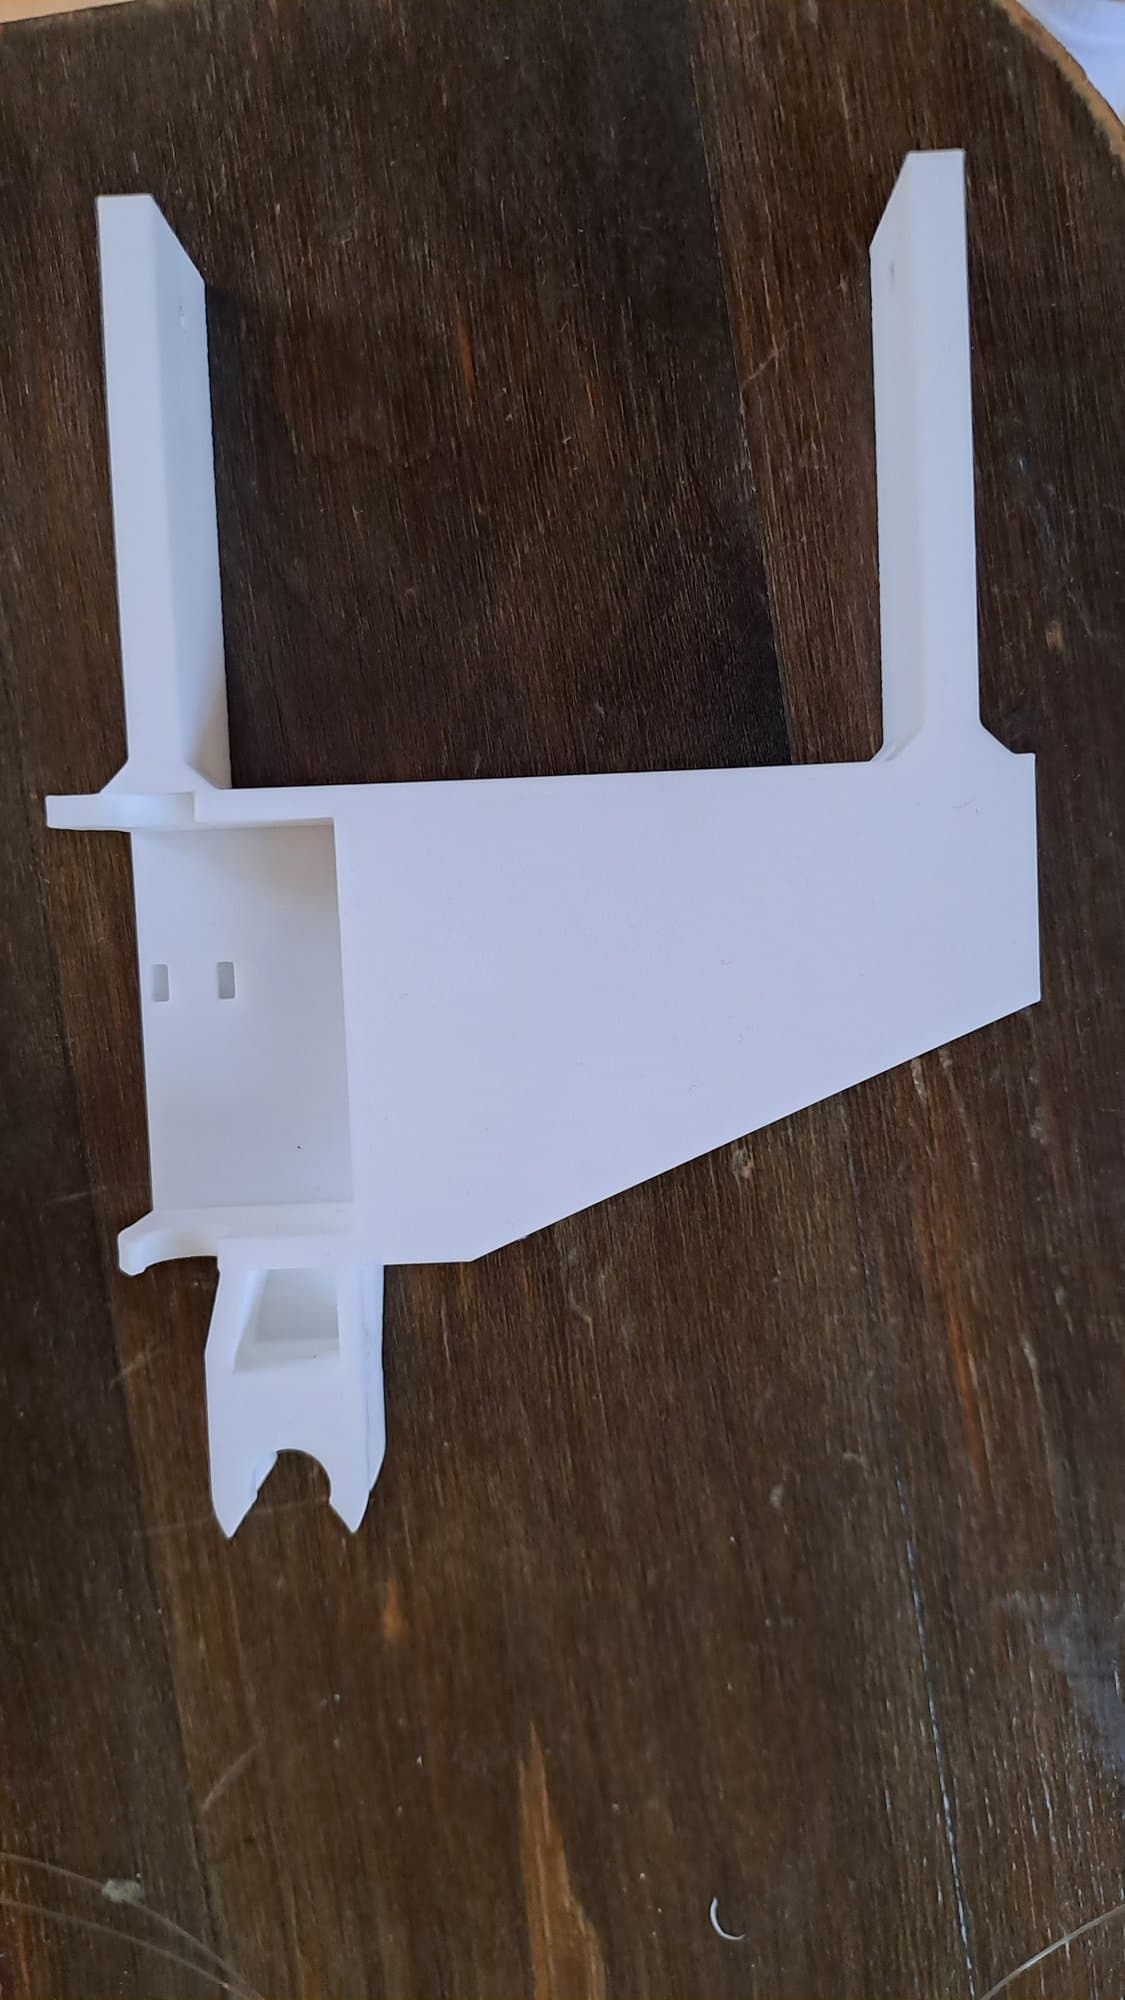
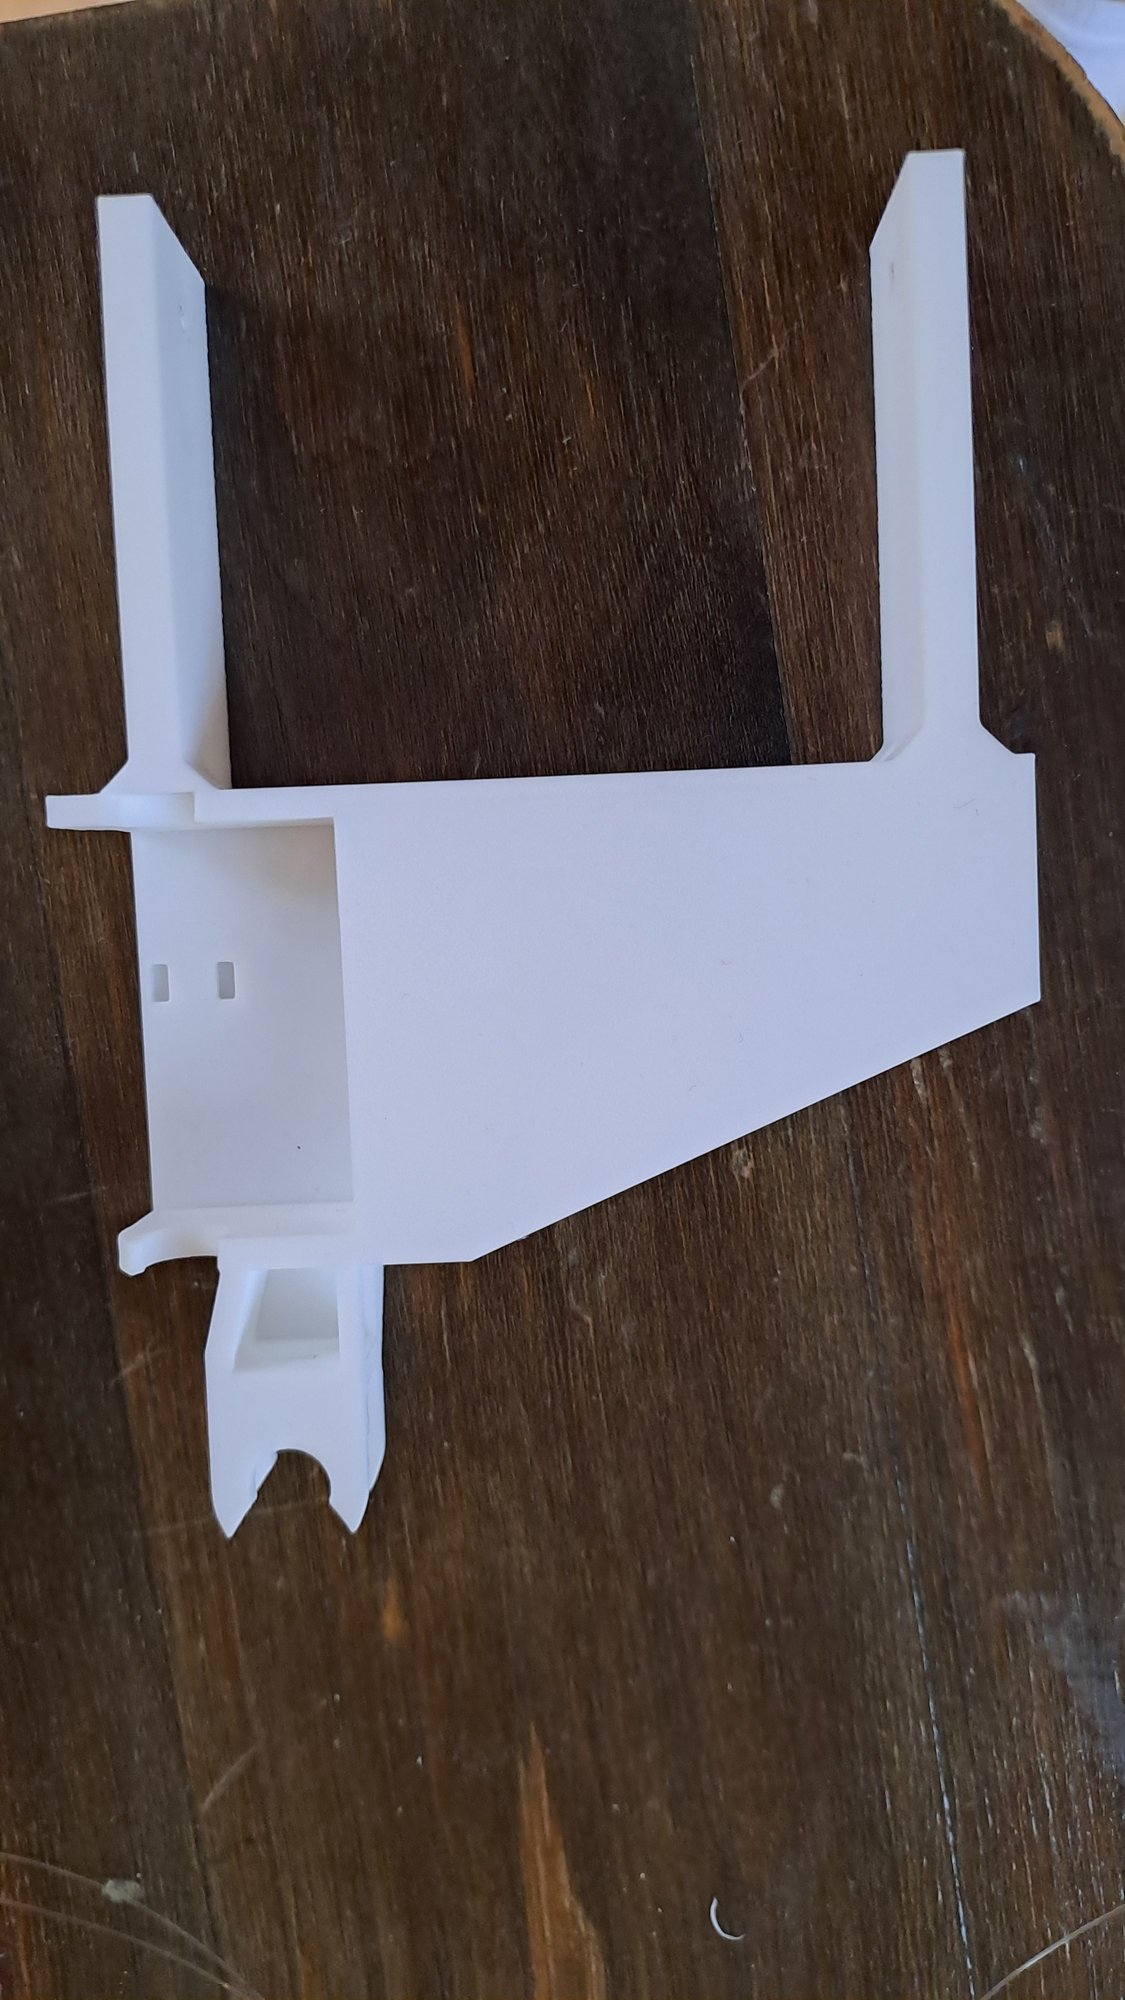
The printed palm frame, before assembly. 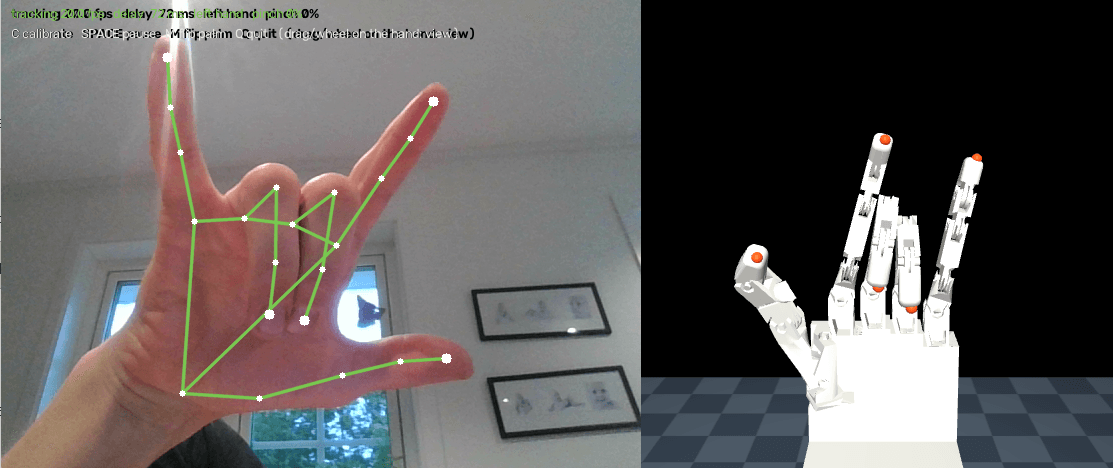
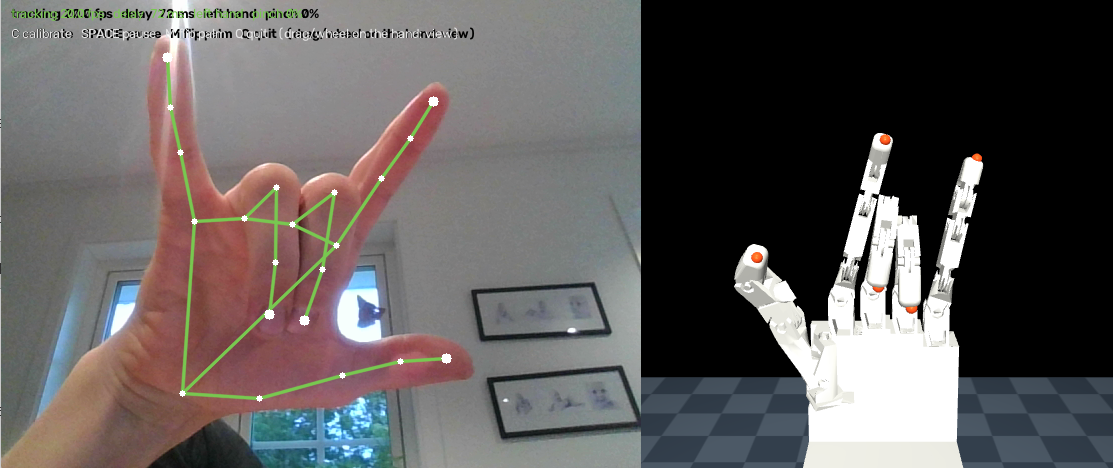
Each finger follows on its own: the simulated hand copies an 'I love you' sign. 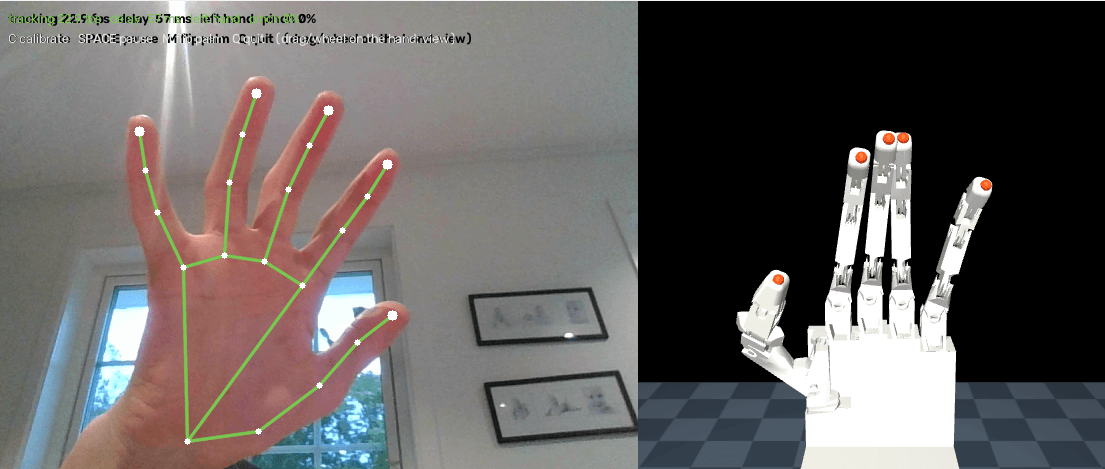
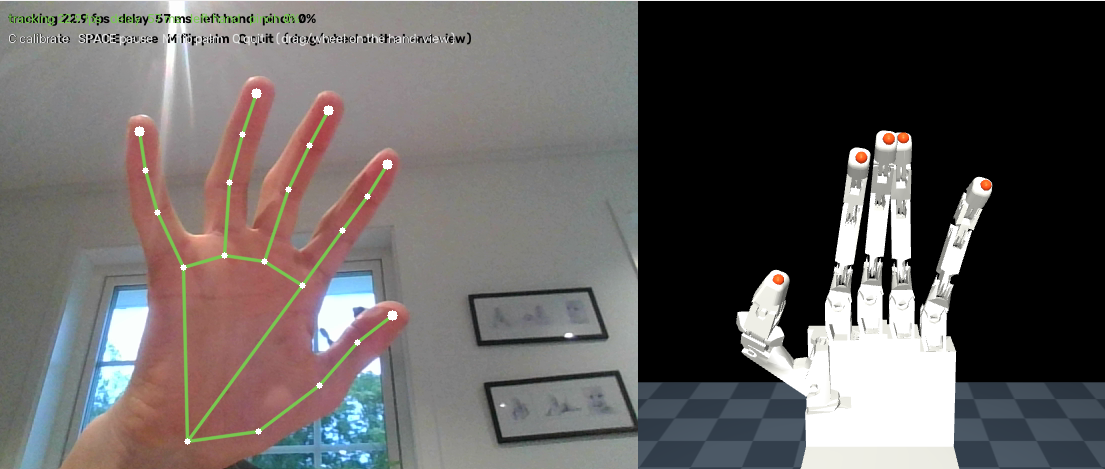
Open your hand in front of the webcam and the simulated hand opens too.