Progress, step by step
Build log
What we tried, what worked, and what didn't. Written as we go.
This is the story of the build, told as it happens. Each post covers one step: what the goal was, what we did, what we found and what comes next. Mistakes included.
For the full lab notebook, with every measurement, see the research log on GitHub.
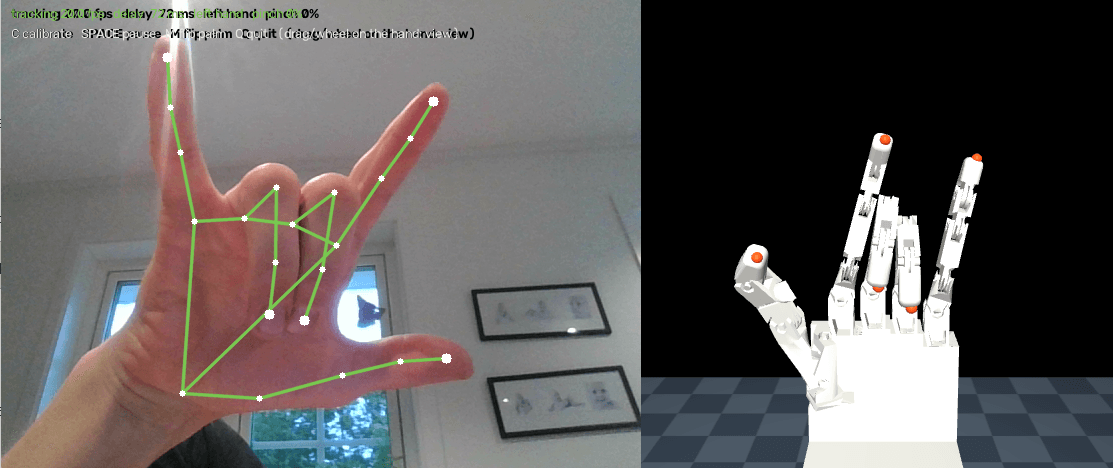
One Python library for the real hand and its twin
The tendra Python package controls the simulated hand and the real hand with the same code, and digital twin v1 sends MuJoCo slider moves to the ESP32.
Read the post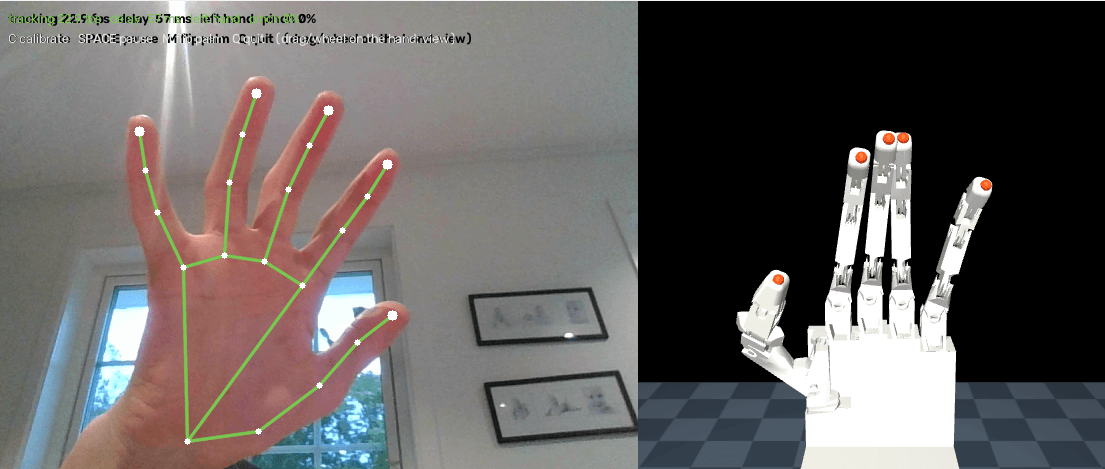
From a CAD export to a working simulation
The Fusion 360 export said the hand weighed 821 g of steel. A small converter script turned it into a 131 g plastic hand that moves correctly in MuJoCo.
Read the post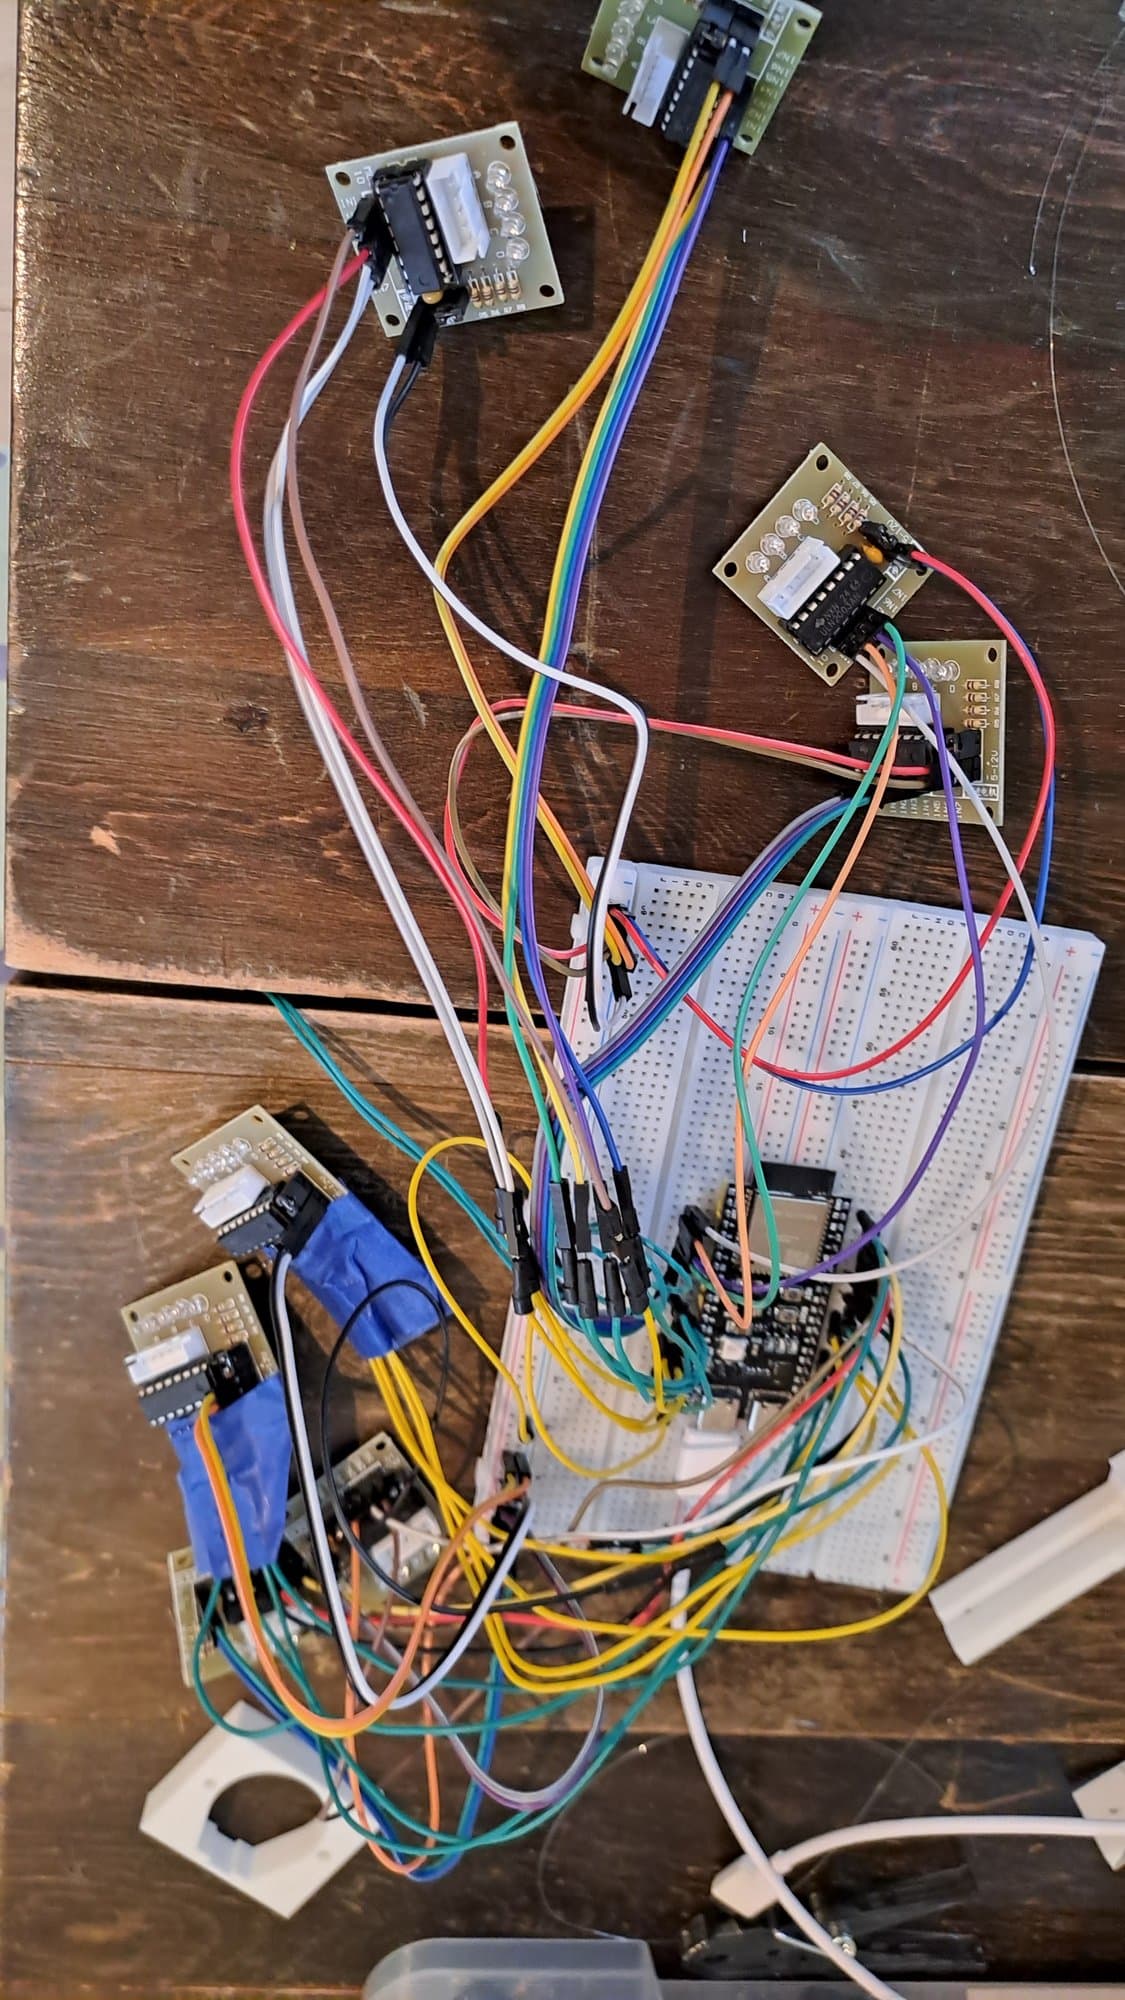
Firmware v0.1: smooth motion for 8 steppers
The first firmware for the ESP32-S3: gentle speed-up and slow-down, all 8 motors moving at once, and a simple text command language. Tested on the computer, not yet on the hand.
Read the post